

Firmware
Real-Time Operating System (RTOS): FreeRTOS on ESP32
A beginner-friendly guide to using FreeRTOS on ESP32 for multitasking firmware with tasks, queues, notifications, mutexes, and practical debugging habits.
6 min read
Notes
Latest build log
A practical ESP32 guide to integrating an NB-IoT/LTE-M modem: choose the network, power it safely, wire UART, use TinyGSM and send first telemetry.
A beginner-friendly guide to using FreeRTOS on ESP32 for multitasking firmware with tasks, queues, notifications, mutexes, and practical debugging habits.
A practical guide to Modbus TCP, Modbus RTU over RS-485, and PLC communication with ESP32 for reliable industrial IoT prototypes.
A practical guide to designing safe OTA firmware updates for ESP32 and STM32, covering partitions, signed images, rollback, rollout control, and delta updates.
A practical ESP32-P4 RISC-V guide: install ESP-IDF, select the esp32p4 target, build a first project, flash over USB, and understand the dual-core architecture.
Learn the three common STM32 interfaces: use UART for debugging, I2C for sensors, and SPI for displays or memory with STM32CubeIDE and HAL.
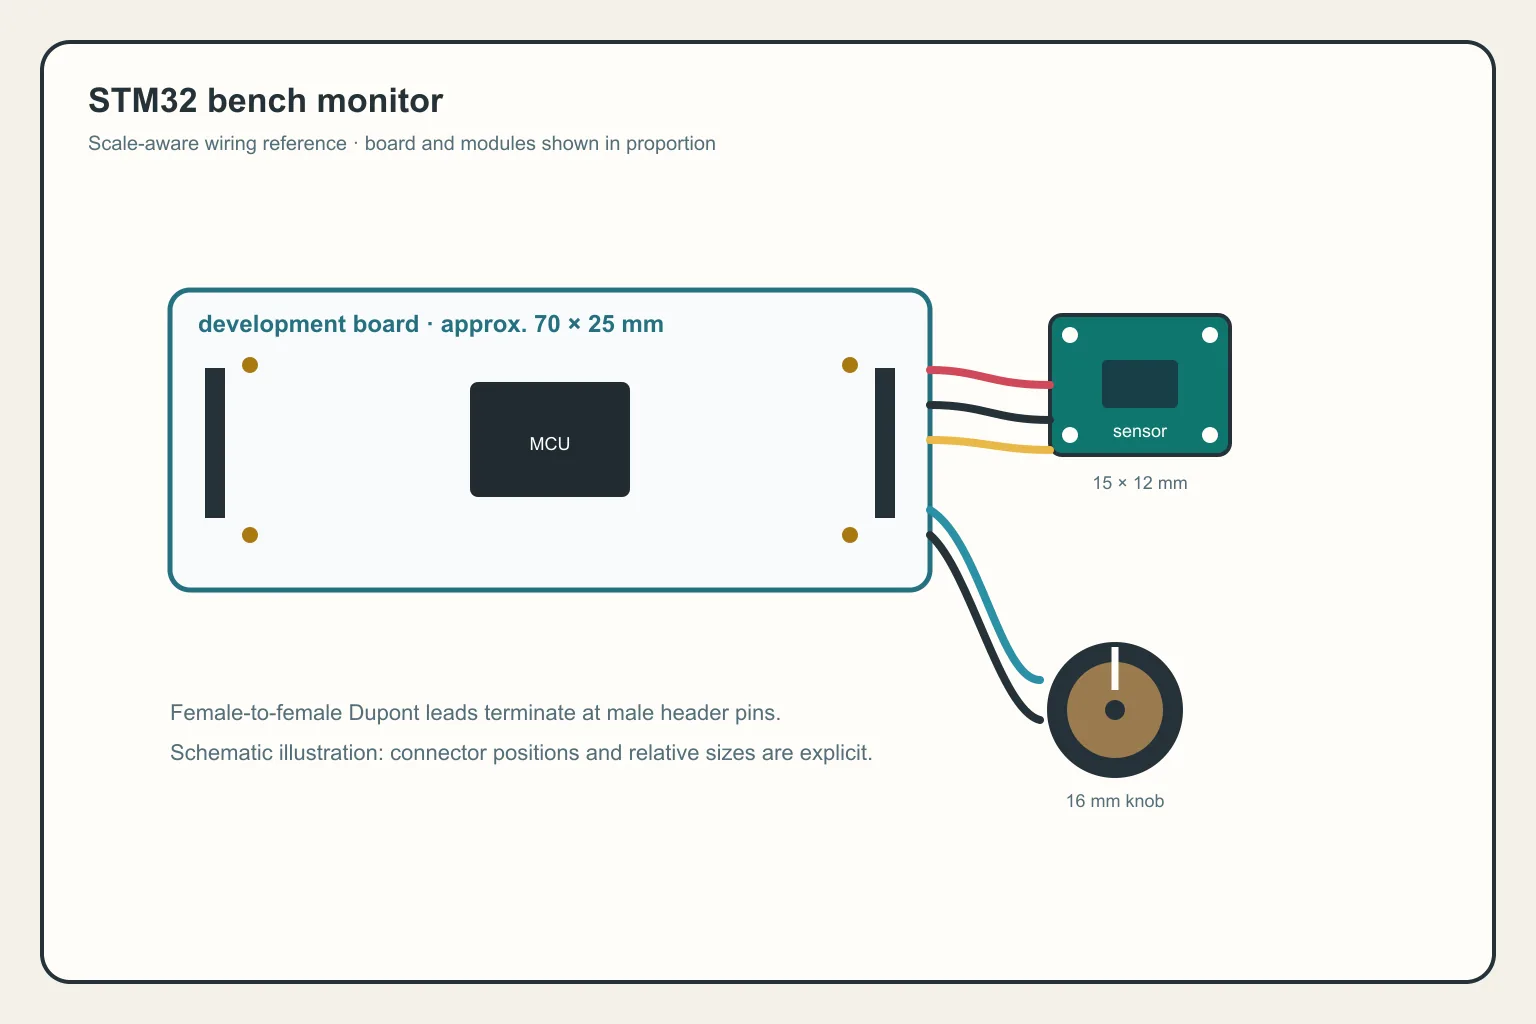
Combine timer, ADC, DMA, PWM, I2C, and UART into a small STM32 bench monitor with a clear firmware architecture, fault handling, and room to grow into a real project.
Learn to configure GPIO, capture a button event with an EXTI interrupt, and create a periodic time base with a timer on STM32CubeIDE using a NUCLEO-G071RB board.
Learn to read analog signals with ADC, control LED brightness with PWM, and transfer multiple samples through DMA on STM32CubeIDE using HAL.
How far can GPT-6 Astra go in KiCad? An independent look at the demo, EEBench, open-source tools, and why routing a board is not the same as making it production-ready.
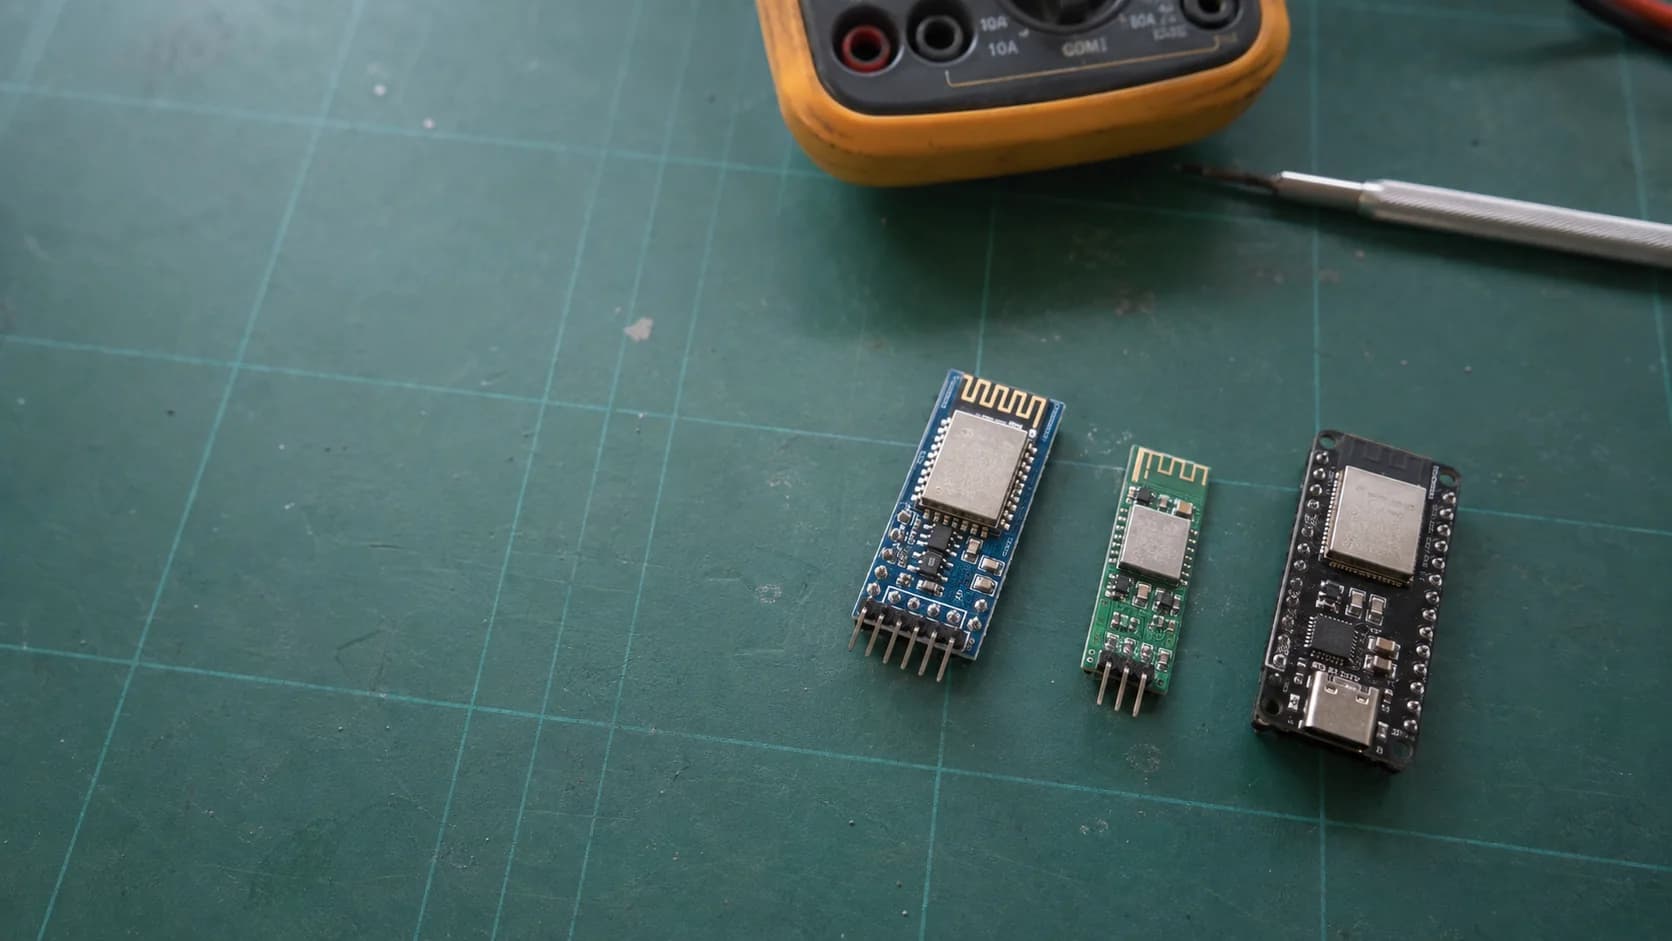
Compare HC-05, HM-10, and BLE 5.0 modules by Bluetooth Classic, BLE GATT, UART, phone support, range, power, and integration for Arduino, ESP32, and IoT projects.
A practical guide to building nRF52840 BLE wearables with open-source references, Zephyr, compact GATT design, sleep/wake states, and real power measurements.
Learn what STM32 is, distinguish chips, modules, and development boards, then choose a practical board for learning GPIO, HAL, STM32CubeIDE, and embedded firmware from the beginning.
A practical comparison of microWakeWord, Google Assistant, and Alexa by architecture, control, privacy, hardware fit, and ESP32-S3 integration.
Connect ESP32 to Wi-Fi, find its IP address, and build a local web server that displays BME280 temperature, humidity, and pressure in a browser.
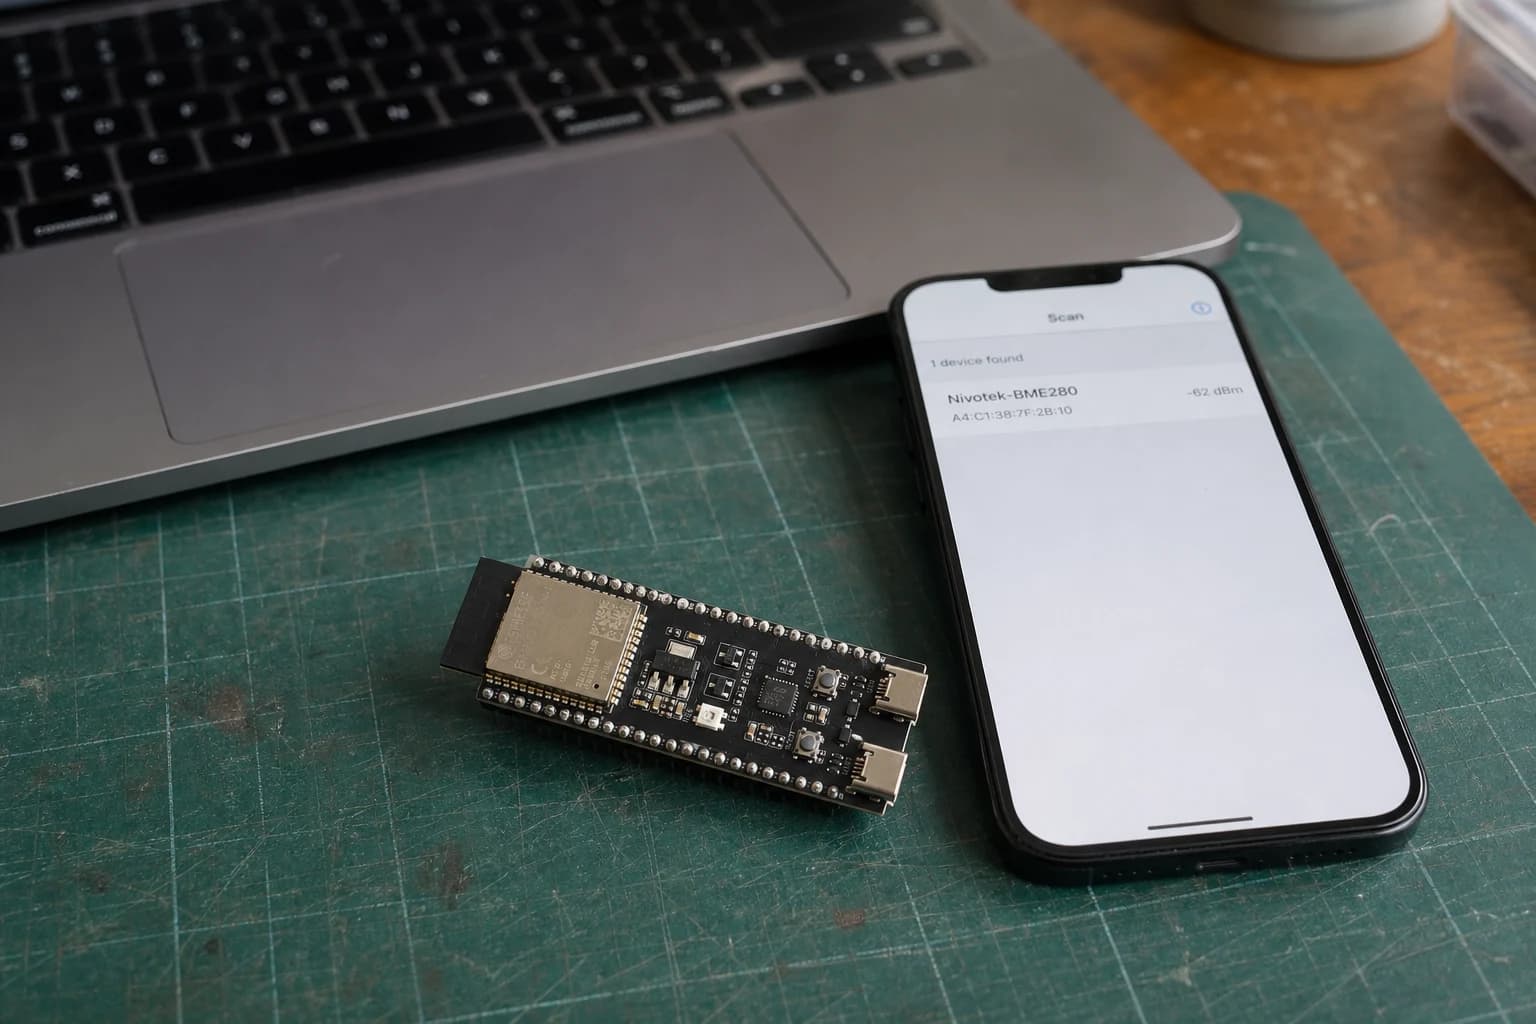
Learn ESP32 BLE, GATT services, and characteristics by sending BME280 readings to a phone with Read and Notify.
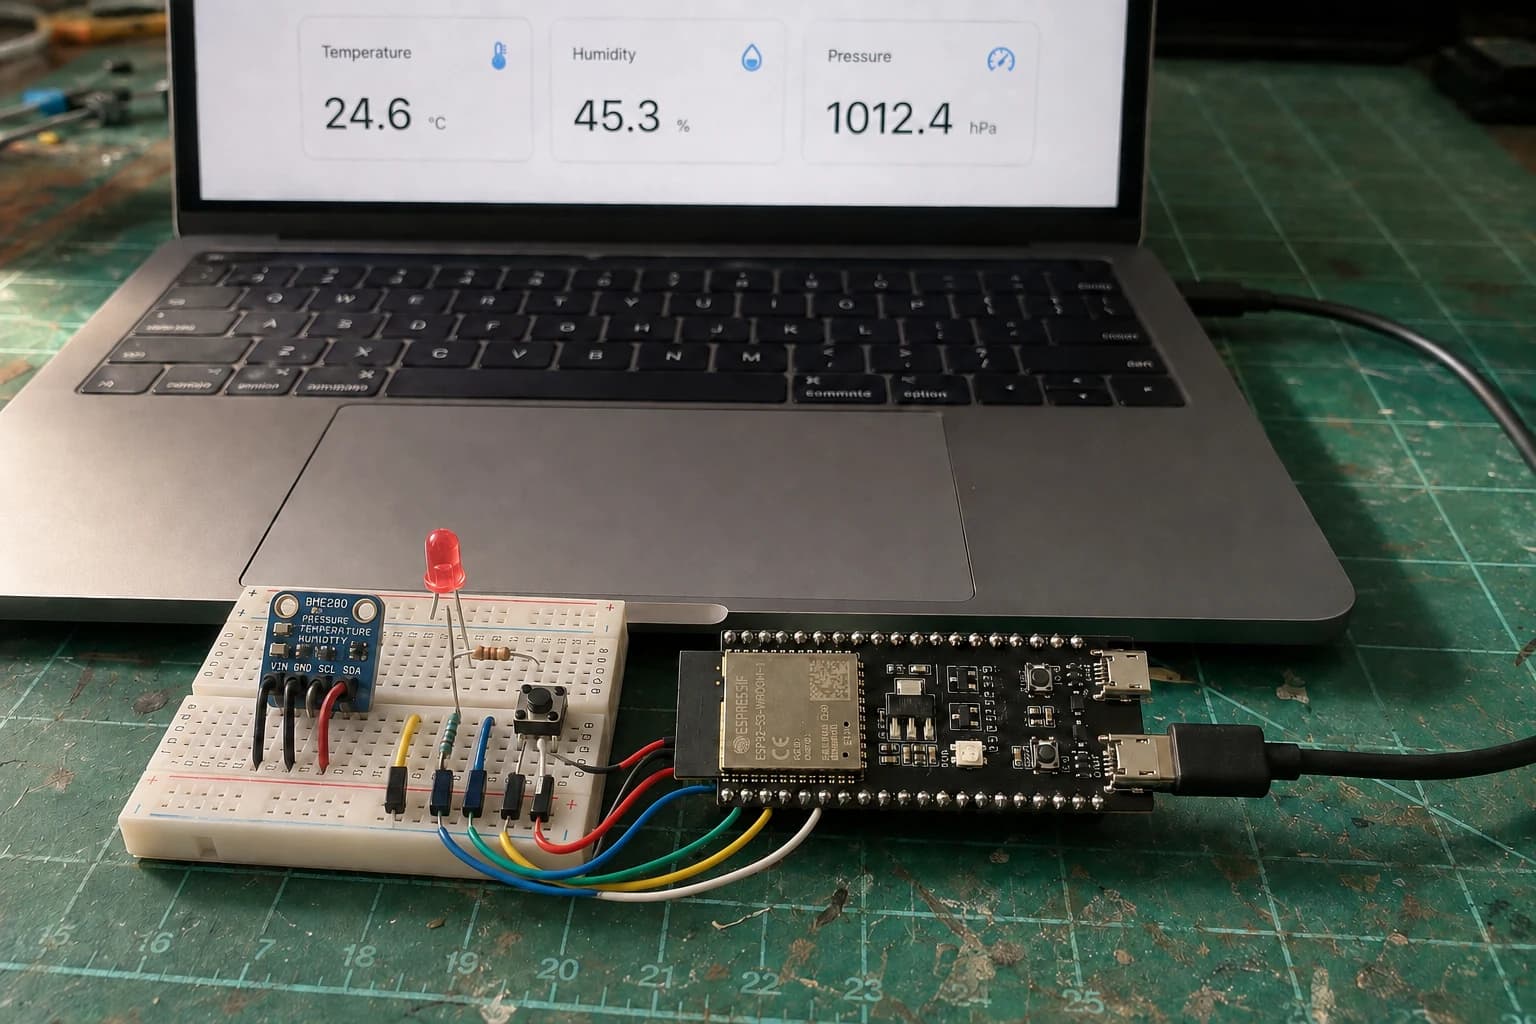
Finish the series with a Room Comfort Monitor: ESP32 reads a BME280, controls a warning LED and serves a local Wi-Fi dashboard.
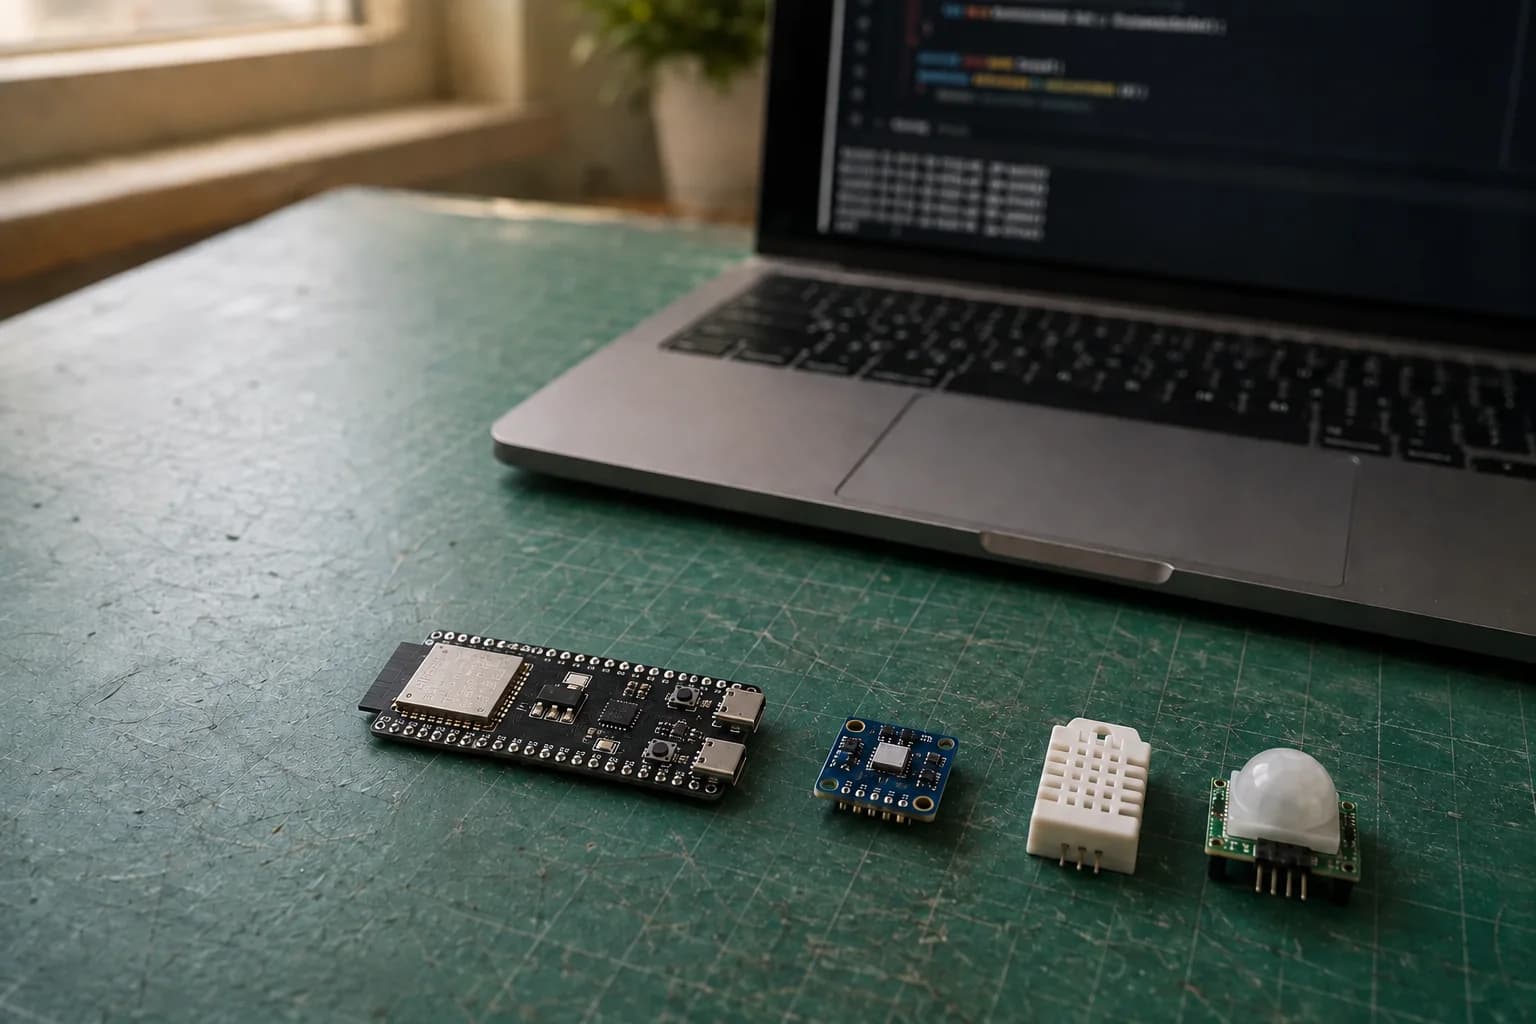
Connect digital, analog, and I2C sensors to ESP32; read temperature, humidity, and pressure from a BME280 and diagnose devices that are not detected.
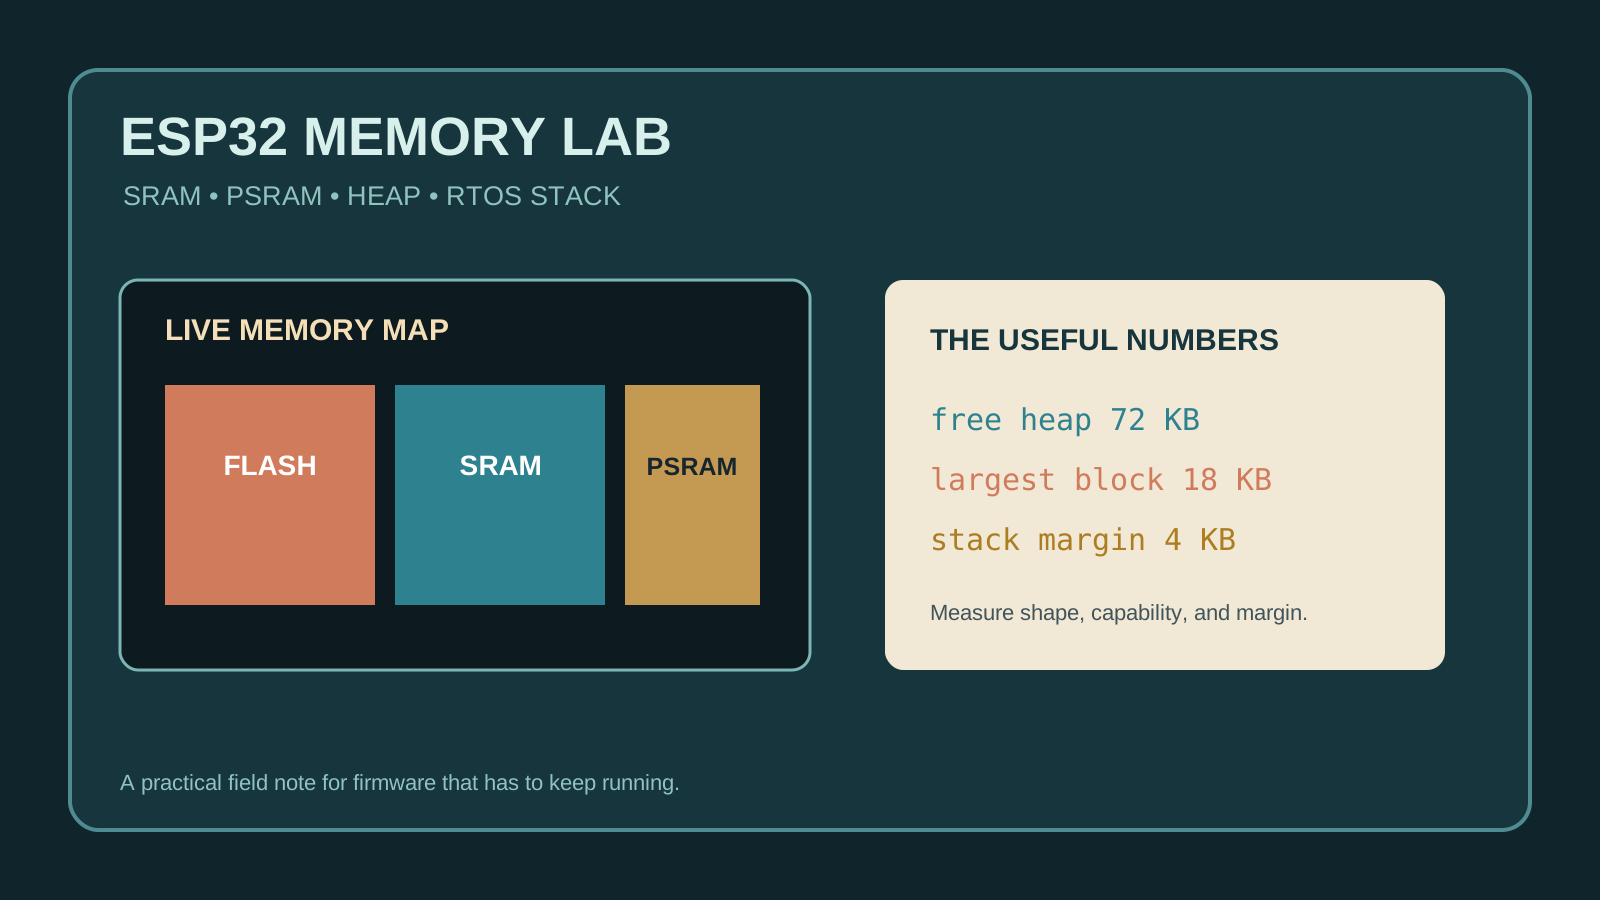
A practical ESP32 memory guide covering SRAM layout, PSRAM usage, heap fragmentation, RTOS task stacks, and small optimization tricks that are useful in real firmware.
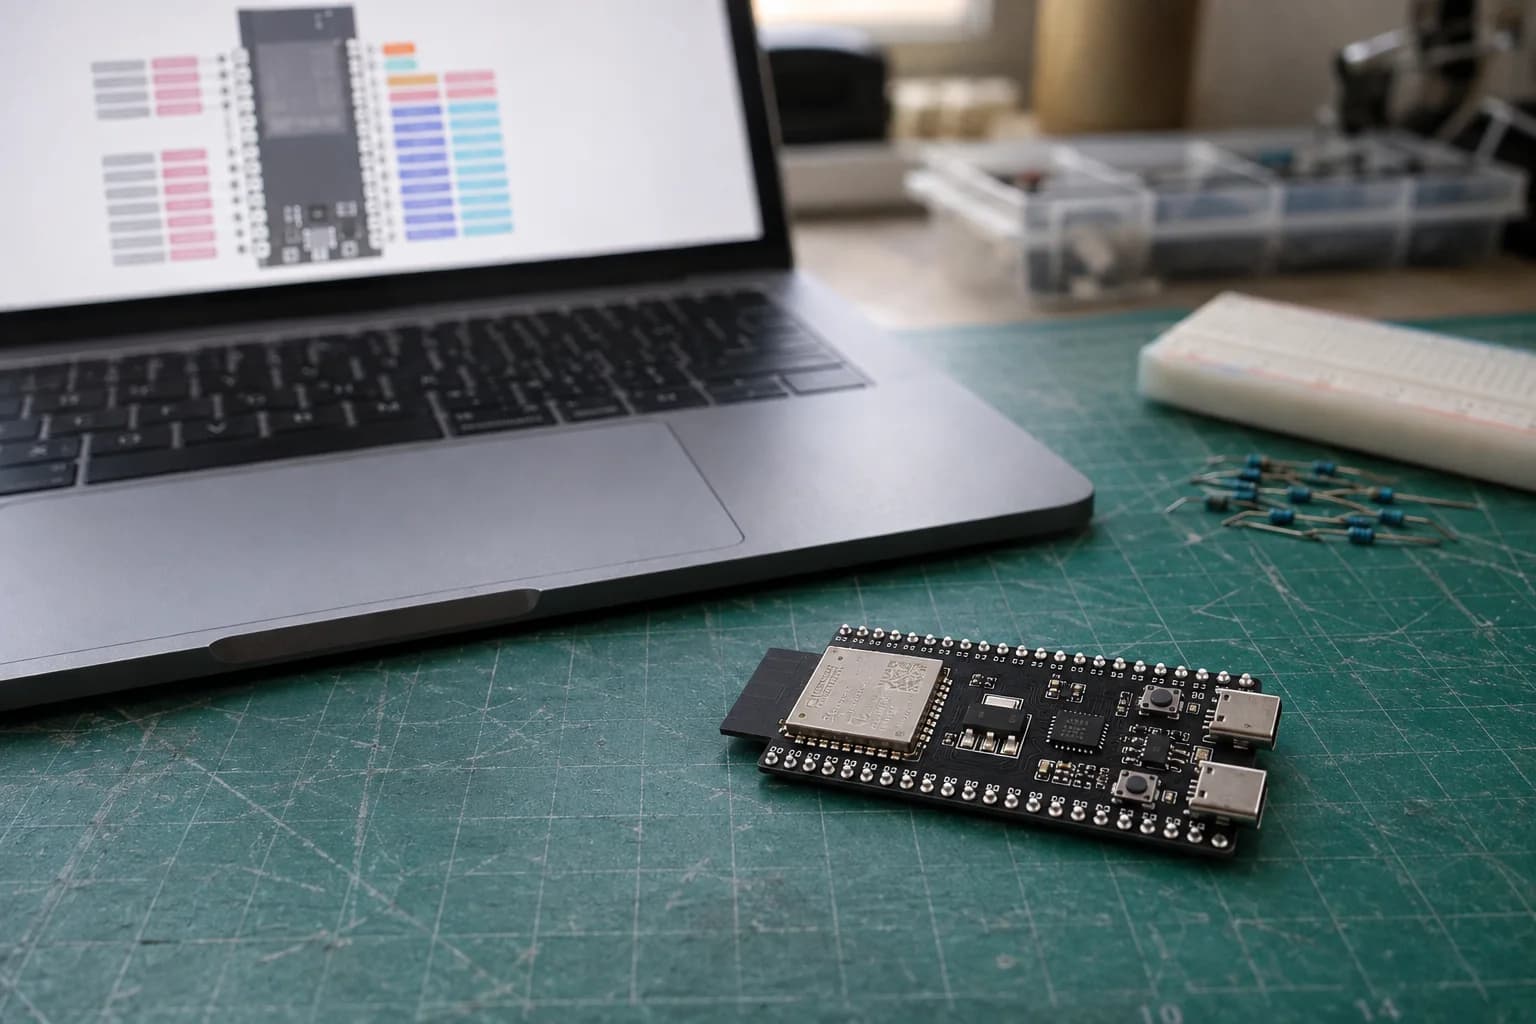
Read an ESP32 pinout, choose GPIO for input and output, use pull-ups, wire an LED and button, and avoid boot, flash, PSRAM, and unsafe 5 V signals.
An interactive ESP32 project roadmap from LEDs and buttons through connected sensors and edge ML to production OTA and security, with practical guides at each level.
Learn the difference between ESP32 chips, modules, and development boards, then choose an ESP32-C3, ESP32-S3, or classic ESP32 board without buying hardware you do not need.
Install Arduino IDE and Arduino-ESP32, select the correct board and port, upload your first sketch, and fix Failed to connect errors on ESP32, ESP32-C3, and ESP32-S3.
How I read ESP32 backtraces and troubleshoot crashes, watchdogs, heap, stack, FreeRTOS, Wi-Fi, ADC, deep sleep, and OTA with a practical runtime checklist.
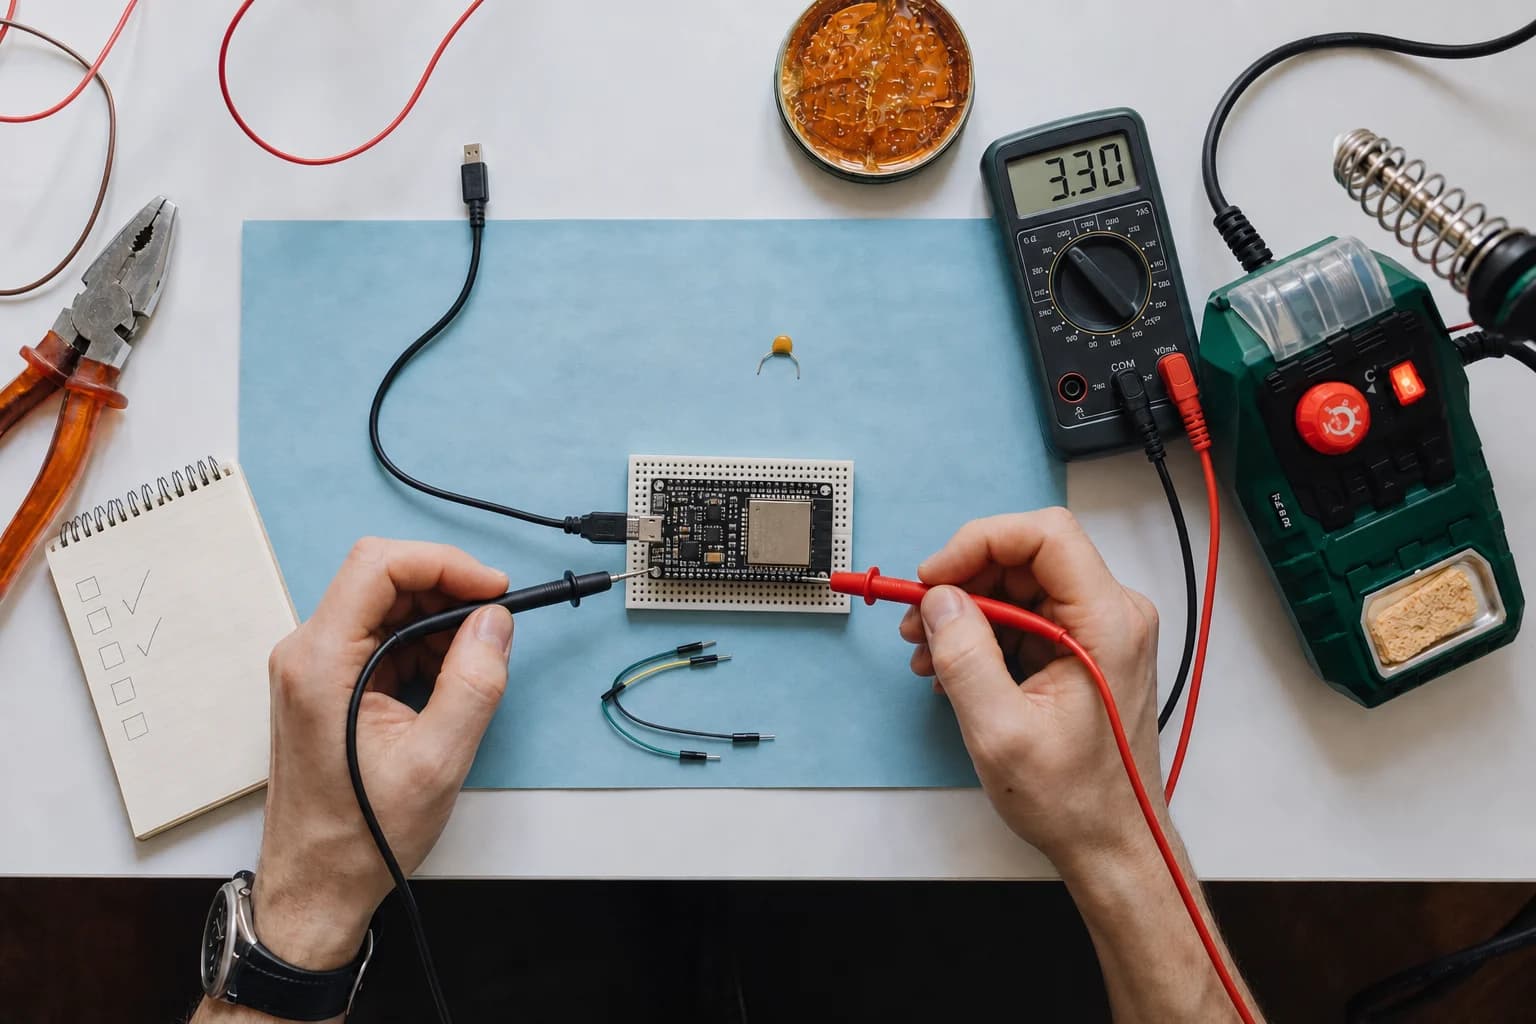
How I troubleshoot eight common ESP32 problems: flashing, boot mode, brownouts, serial, GPIO, I2C, SPI, and custom PCB bring-up.
A practical look at local wake-word detection on ESP32-S3 devices: audio framing, microWakeWord, threshold tuning, false activations, microphone mute, and privacy.
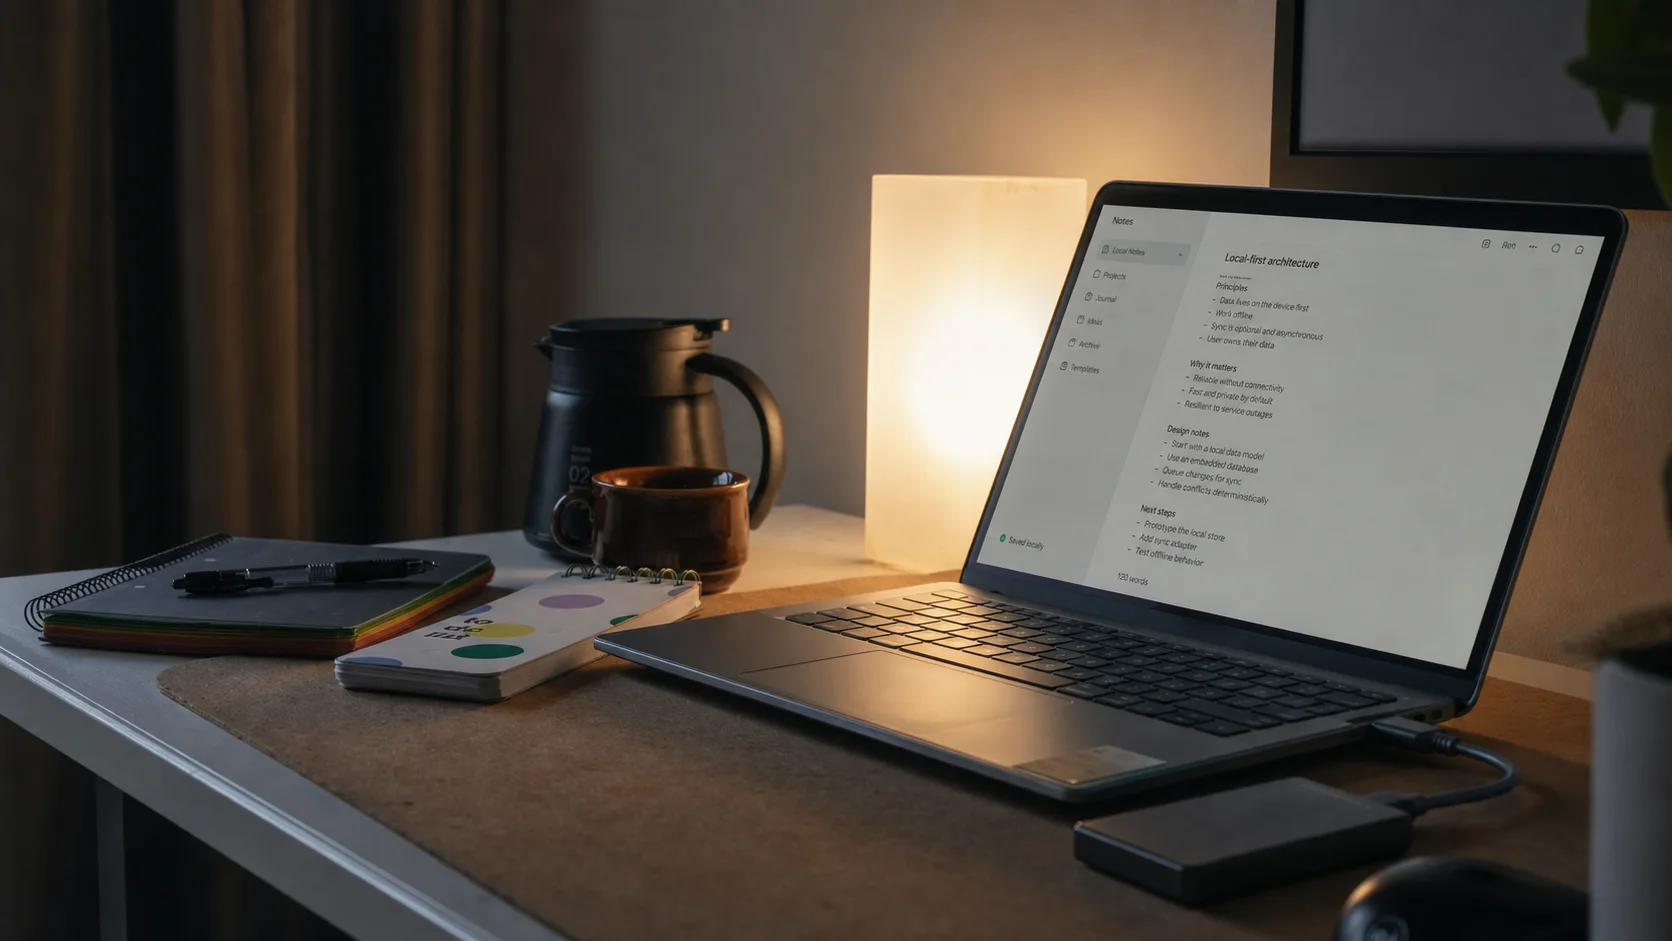
A practical local-first architecture using an on-device store, Automerge, optional sync, and backups so an app stays useful without sending its working data to a cloud service.
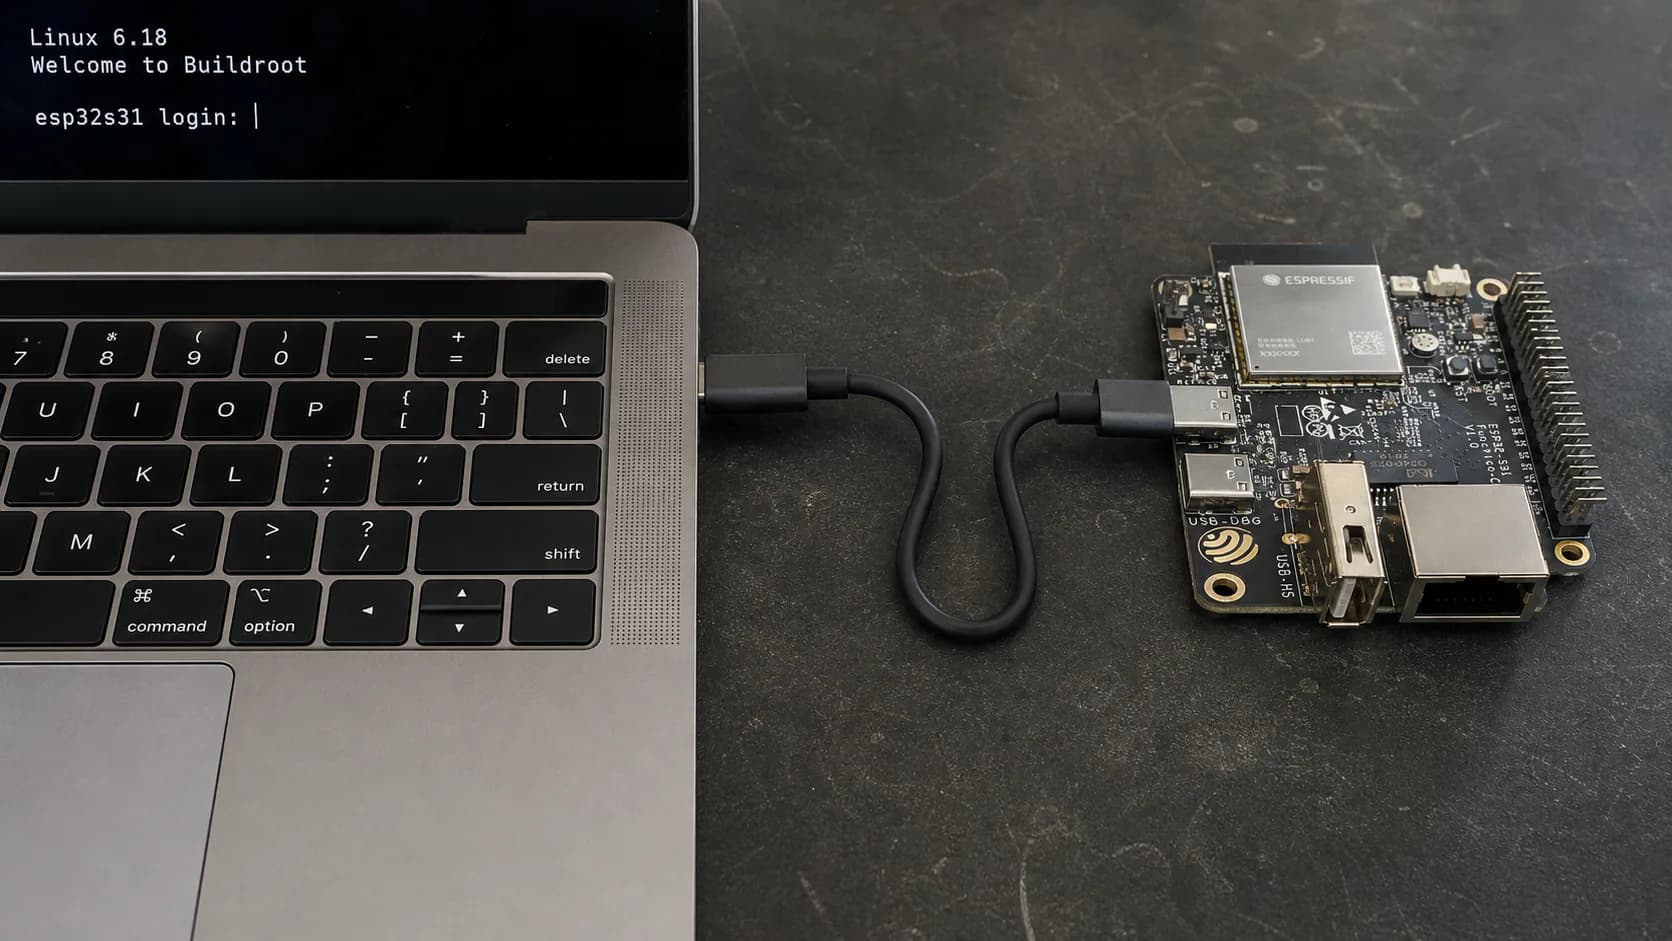
ESP32-S31 now has an official Linux BSP Developer Preview. Here is a practical look at its MMU, Buildroot, U-Boot, Linux 6.18, build flow, and the limits that still matter.
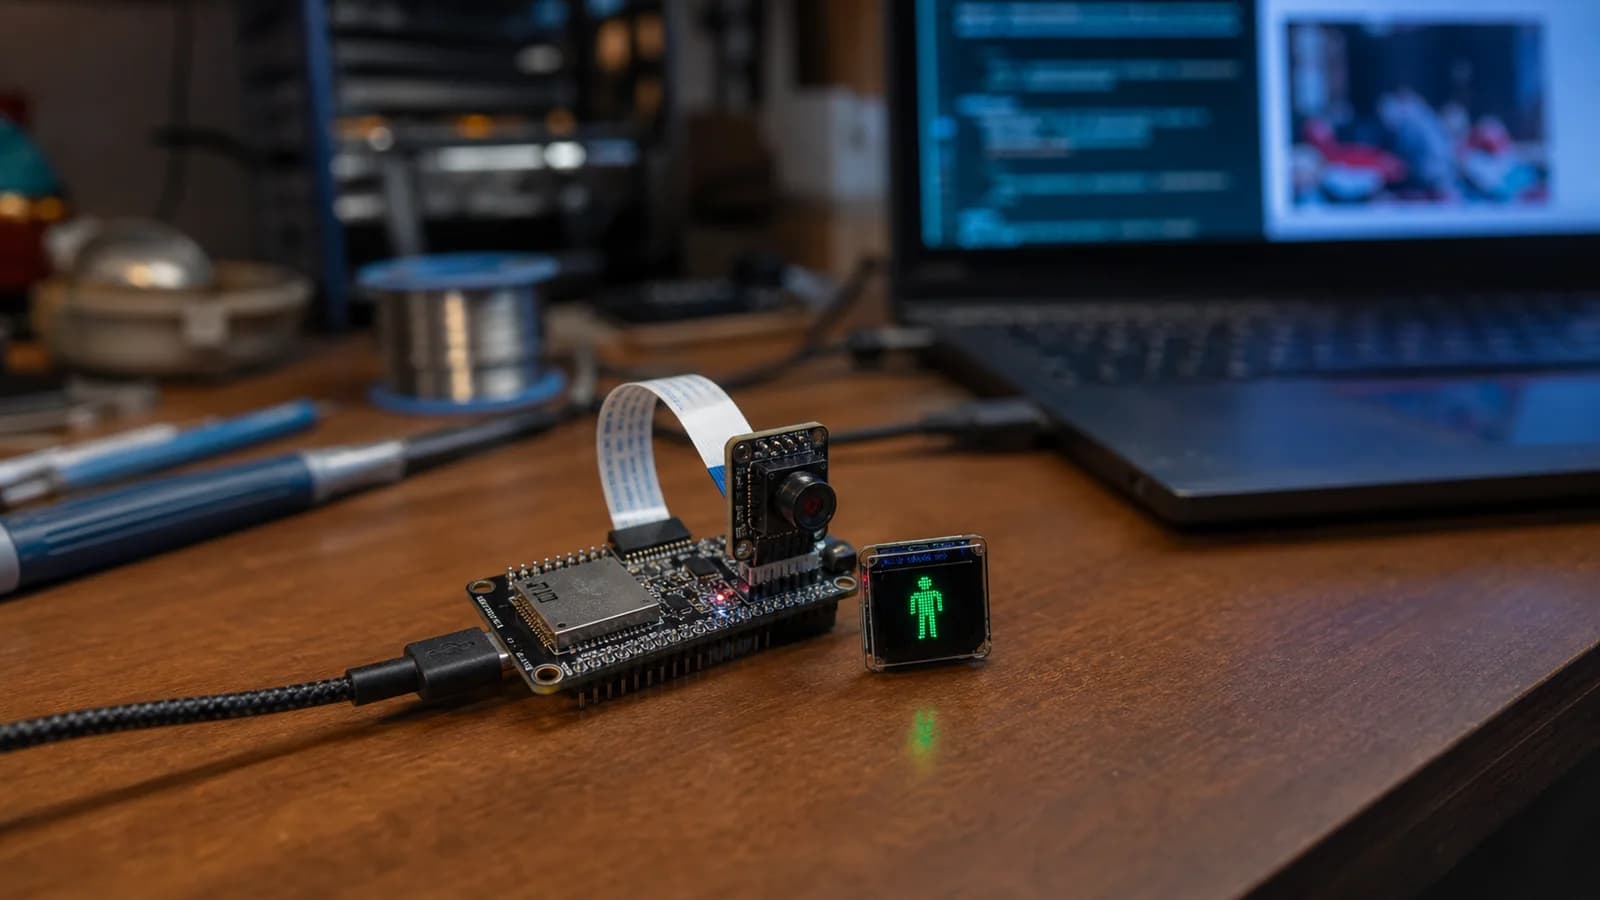
How I run a small person-detection model on ESP32 with TensorFlow Lite Micro and ESP-NN, from memory limits to testing Espressif's example.
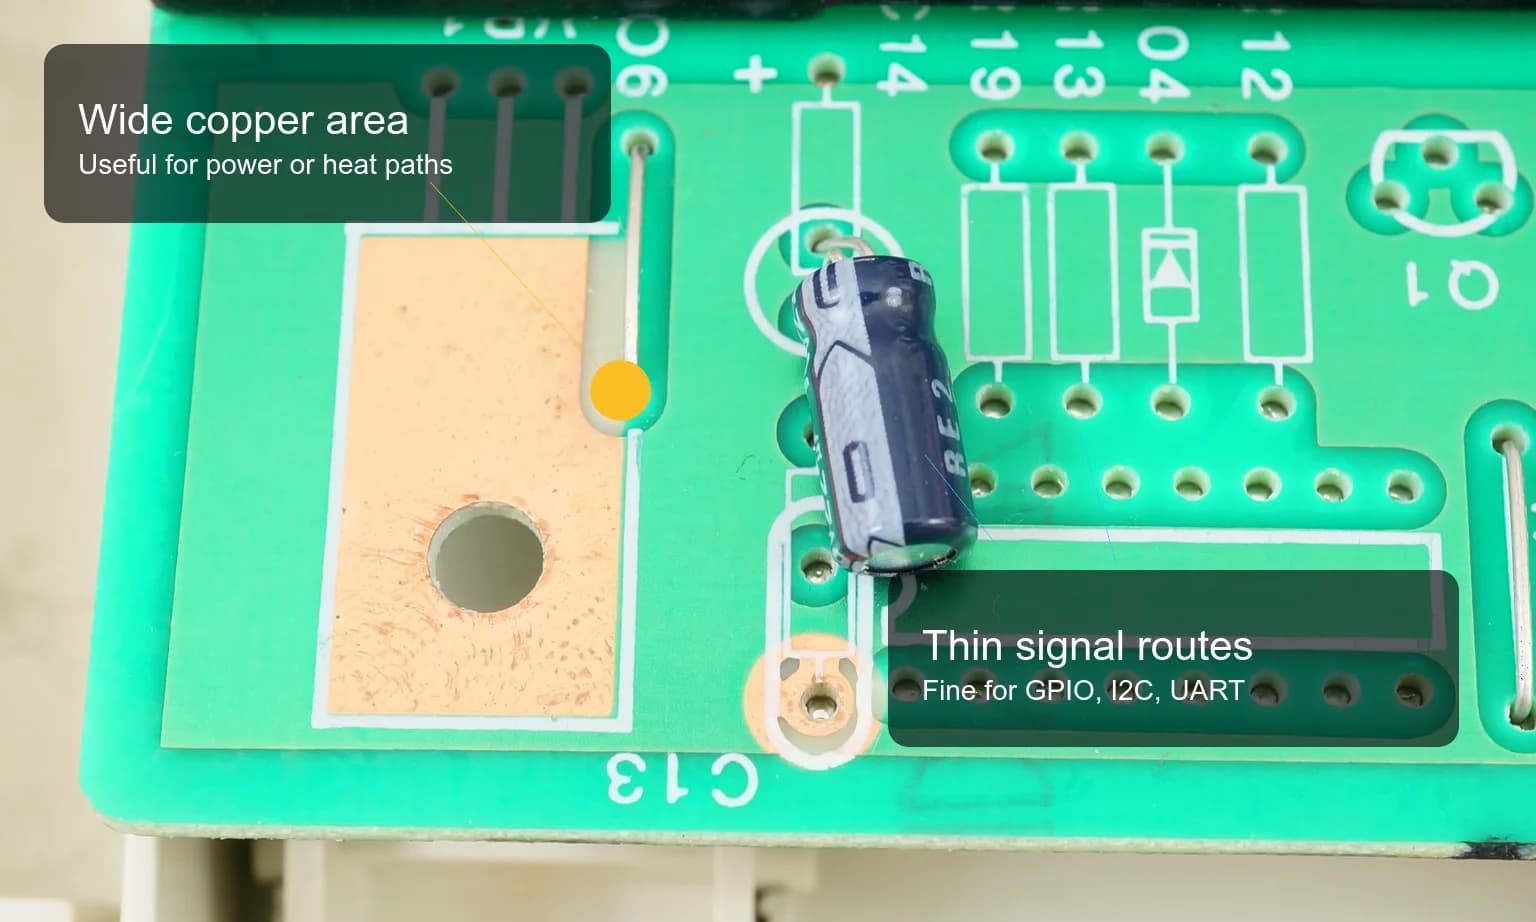
A practical guide to PCB net classes and trace width for small boards: signal traces, 3V3, 5V, battery paths, ground, power vias, and a pre-Gerber checklist.
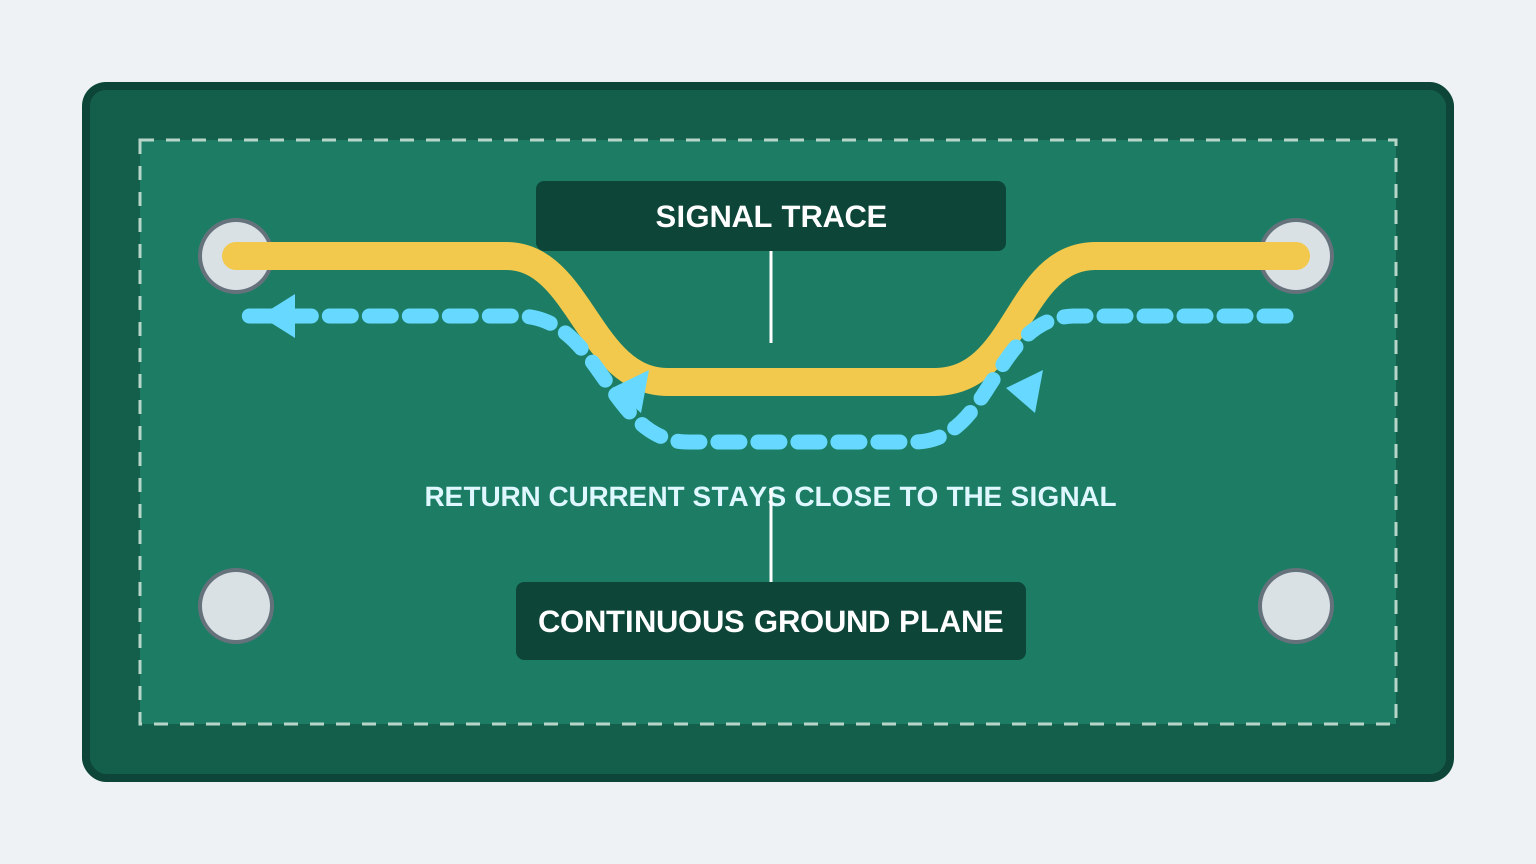
A practical guide to PCB ground planes, return current, GND layout mistakes, stitching vias, decoupling paths, and copper pour checks.
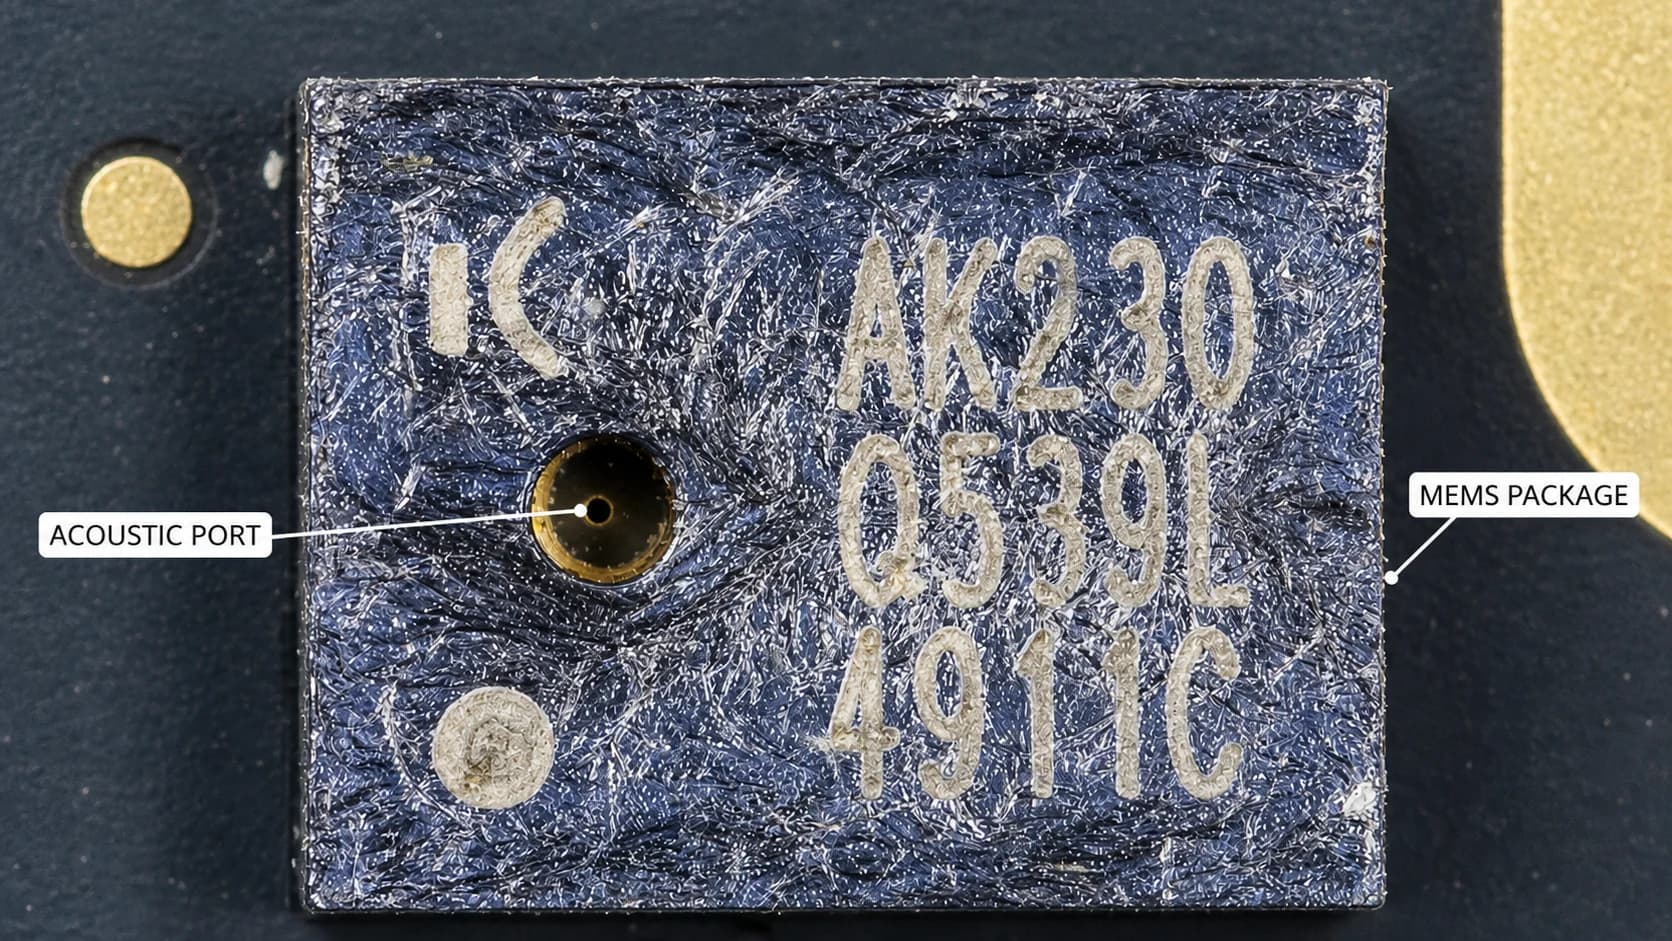
Learn how MEMS microphones work, how analog, PDM, and I2S outputs differ, and how to avoid PCB, power, and acoustic-port mistakes.
A beginner guide to choosing capacitors for circuits: capacitance, voltage rating, decoupling, ceramic types, DC bias, and ESP32 values.
A beginner-friendly SMD soldering guide covering tools, easy parts, resistors, capacitors, multi-pin ICs, flux, hot air, and PCB inspection.
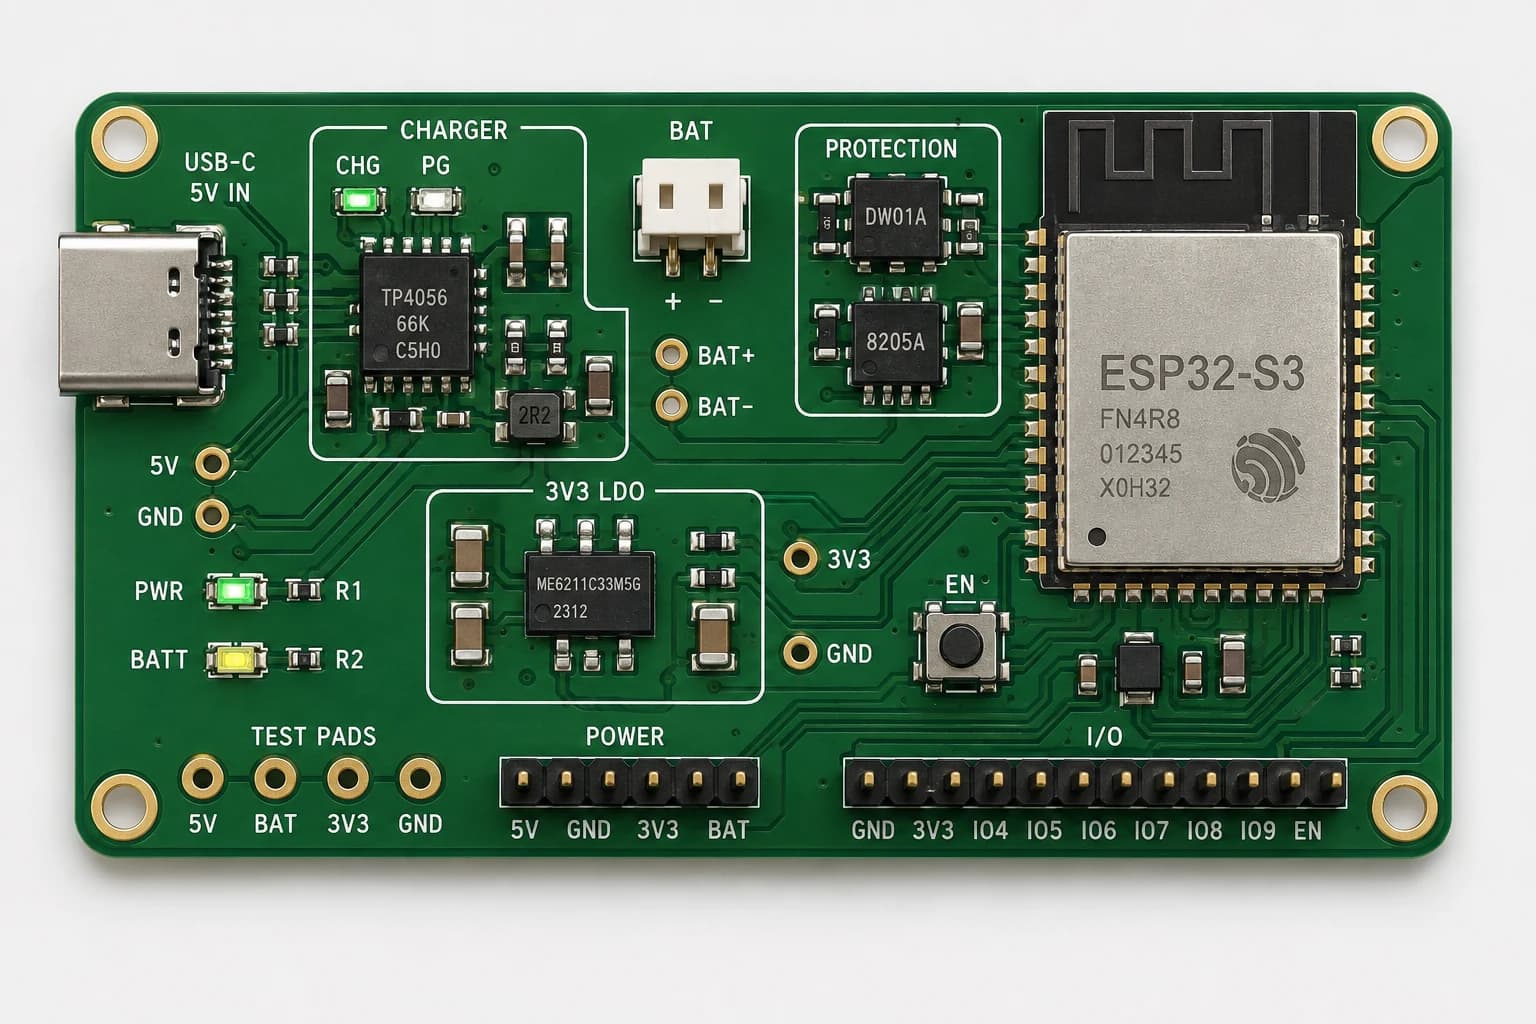
Review an ESP32-S3 battery power path from USB-C and TP4056 charging to protection, load sharing, 3.3V regulation, and load budget.
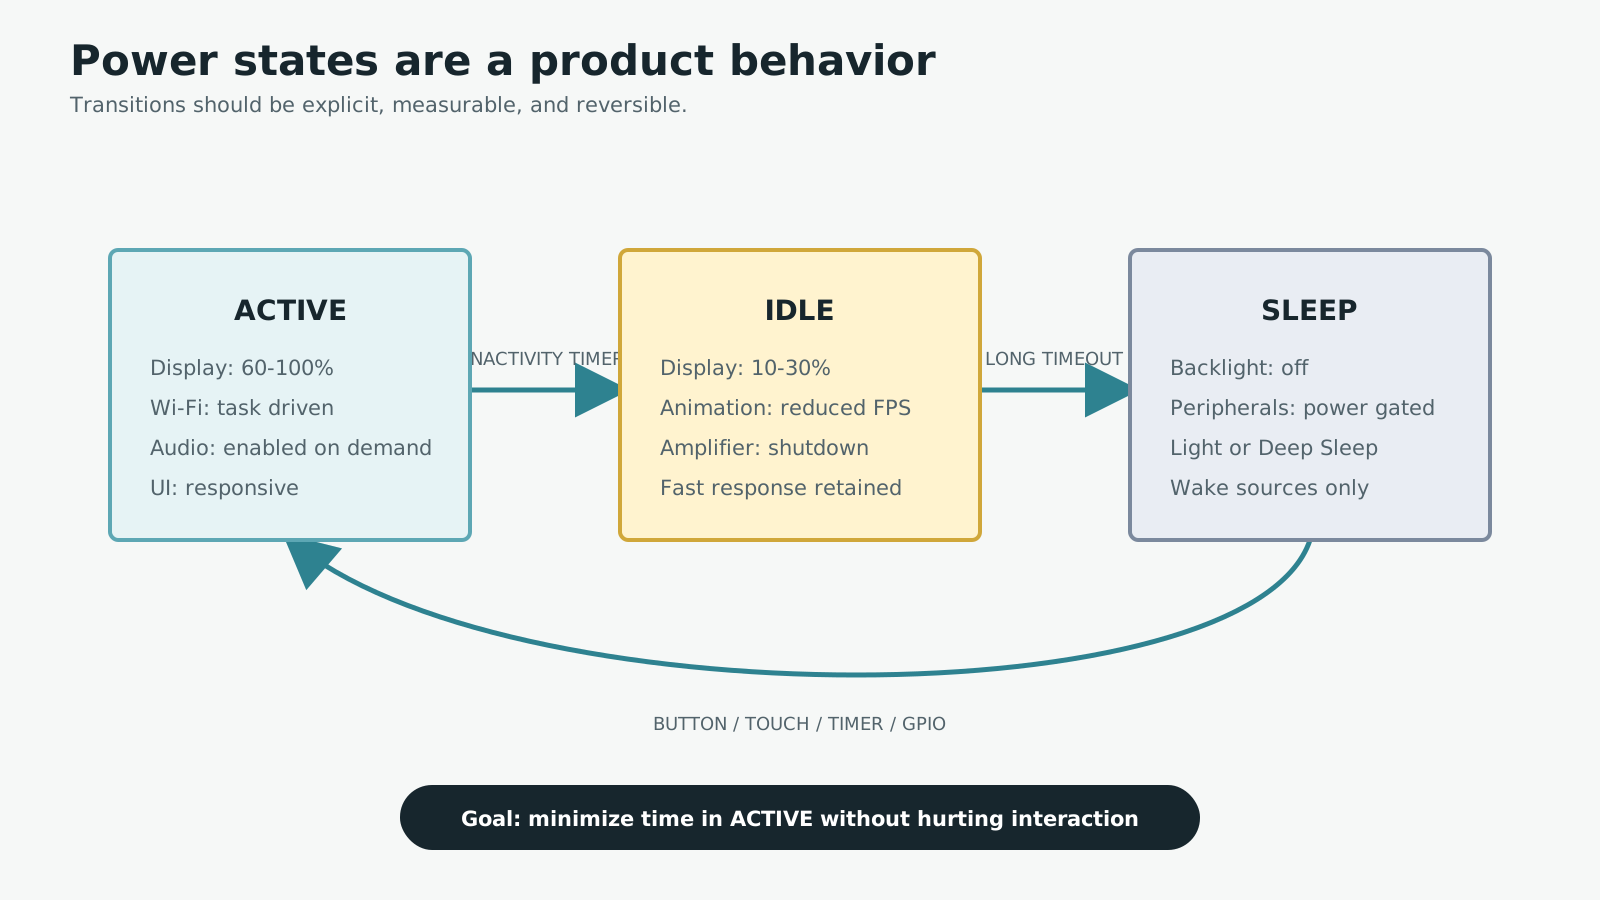
Analyze battery life for an ESP32 robot with a display: backlight, Wi-Fi, audio, peripherals, sleep modes, wake sources, and runtime.
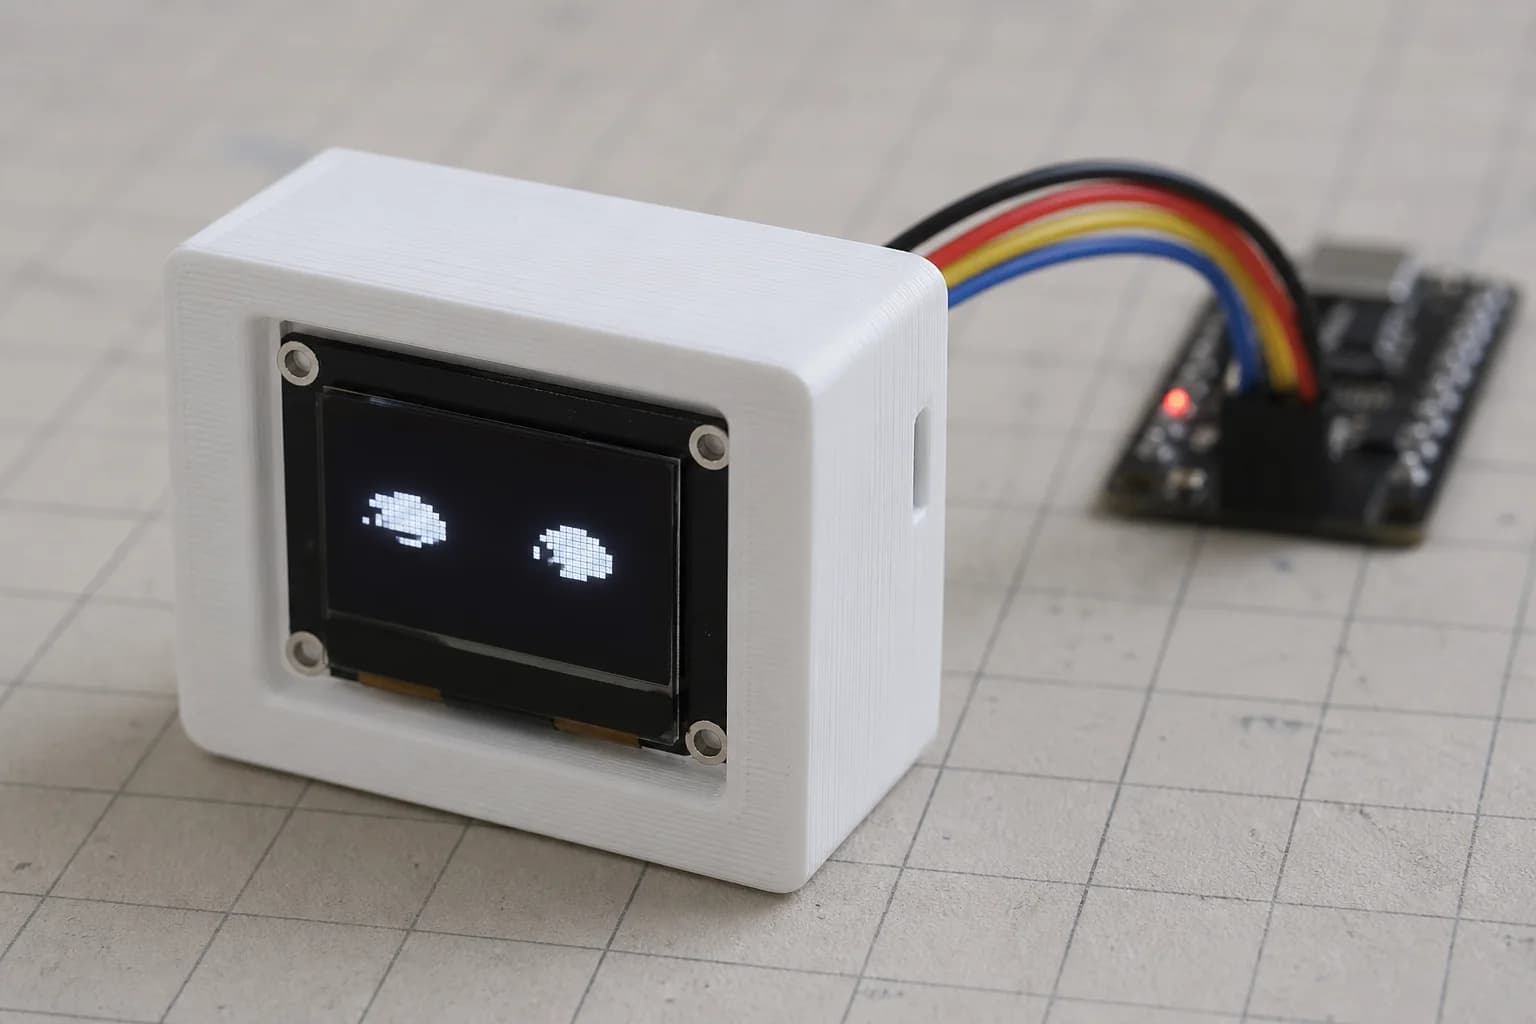
Build a Mochi Robot emotion state machine for idle, listening, talking, happy, sad, thinking, and error states with replaceable animations.
A practical PCB review checklist before fabrication: schematic, ERC, footprints, clearance, power, antenna, USB pairs, silkscreen, Gerbers, and BOM.
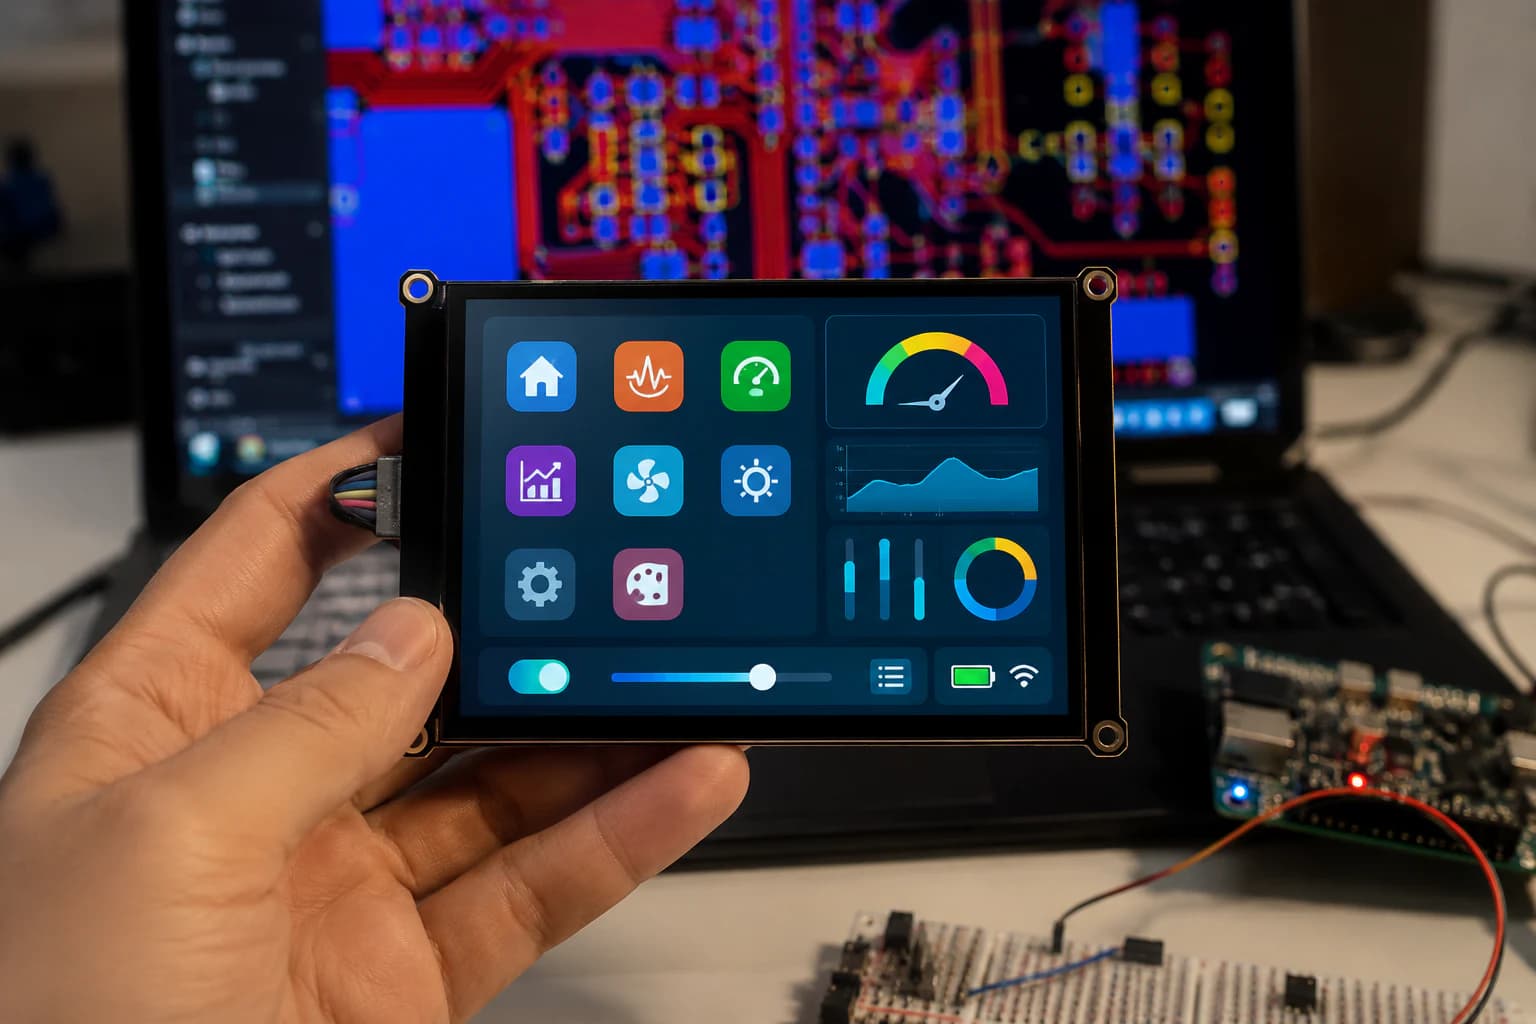
A practical guide to animated GIF expressions in ESP32 firmware: convert assets, enable LV_USE_GIF, store files, and render with lv_gif.
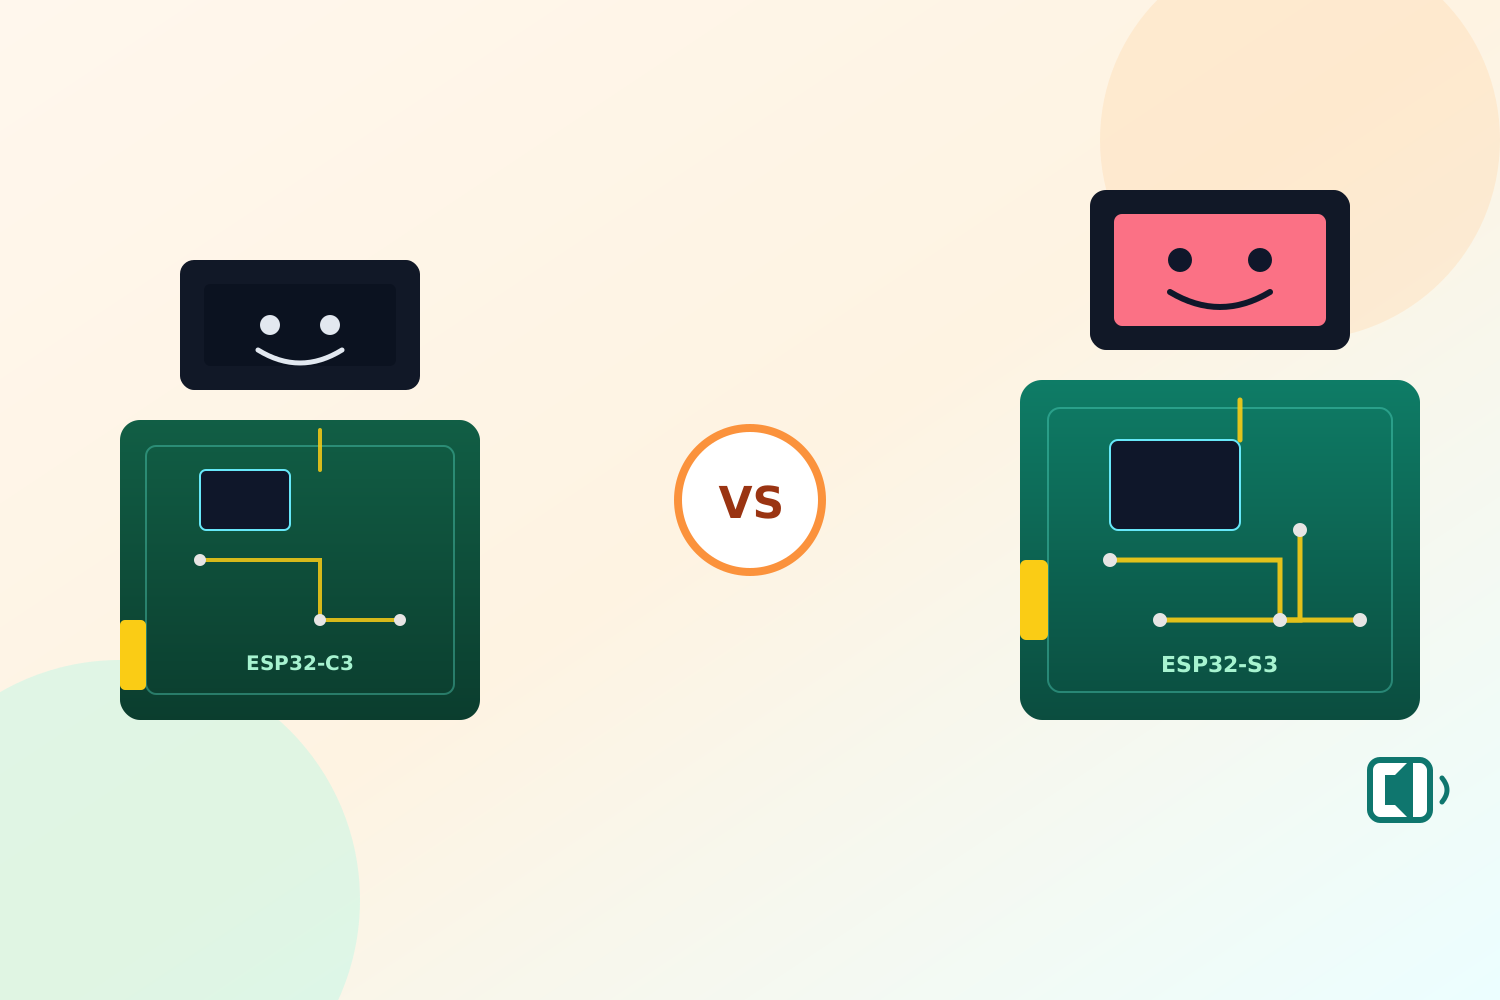
Comparing ESP32-C3 and ESP32-S3 on GPIO, RAM, PSRAM, USB, I2S, and LVGL headroom, with a concrete recommendation for a basic Mochi build and a Mochi AI build.
Compare GIF, PNG, JPG, and C array images for ESP32 displays by flash use, RAM use, decode speed, alpha, animation, and quality.
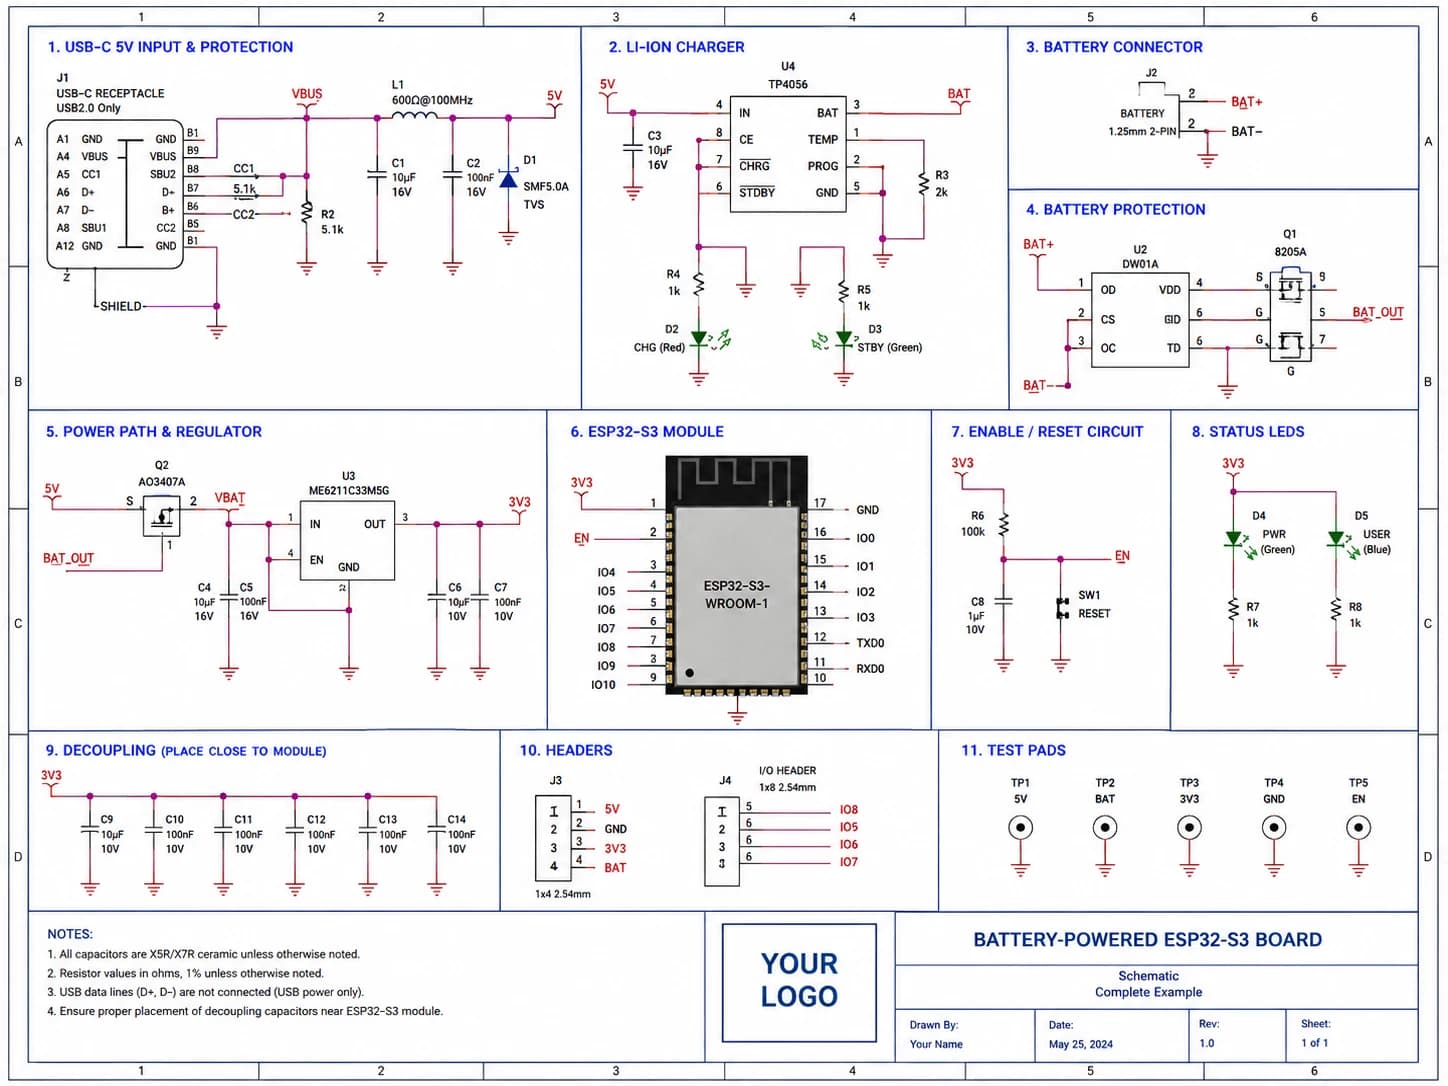
An ESP32 TouchDown case study for reviewing an open-source schematic before reuse, covering power, reset, boot, USB, connectors, and tests.
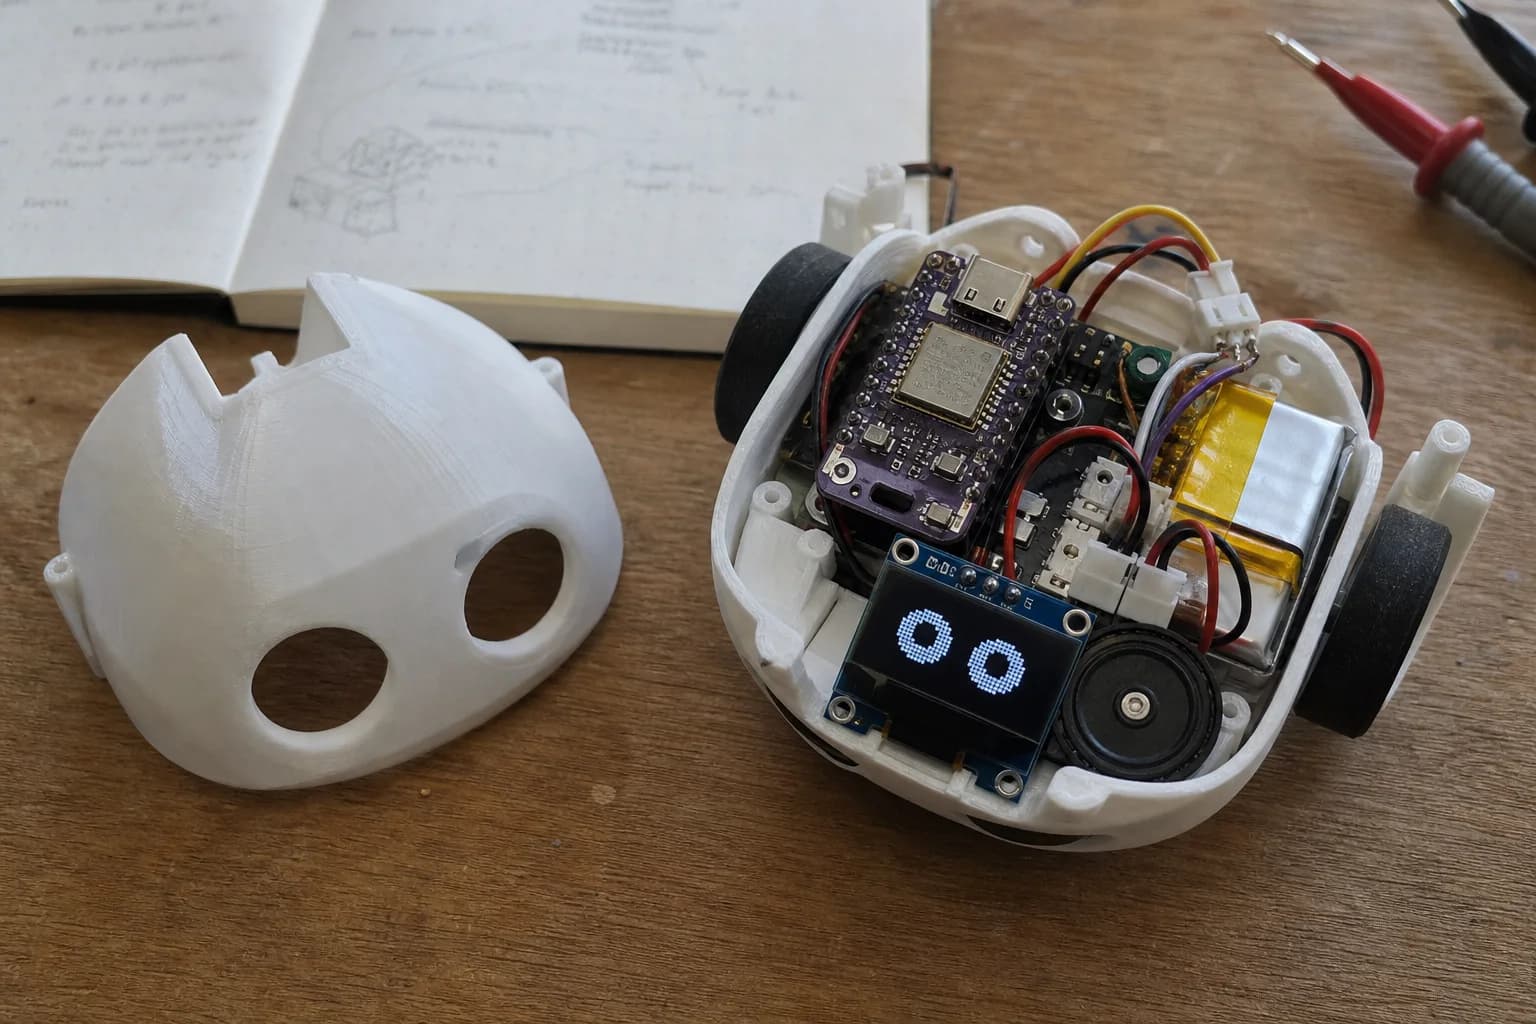
A practical explanation of BCLK, WS, DIN, DOUT, full-duplex audio, sample rate, and buffers when building two-way I2S audio on ESP32-S3.
A practical breakdown of ESP32-S3 Mochi Robot hardware: display, touch, I2S microphone, amplifier, speaker, battery, charging, and GPIO.
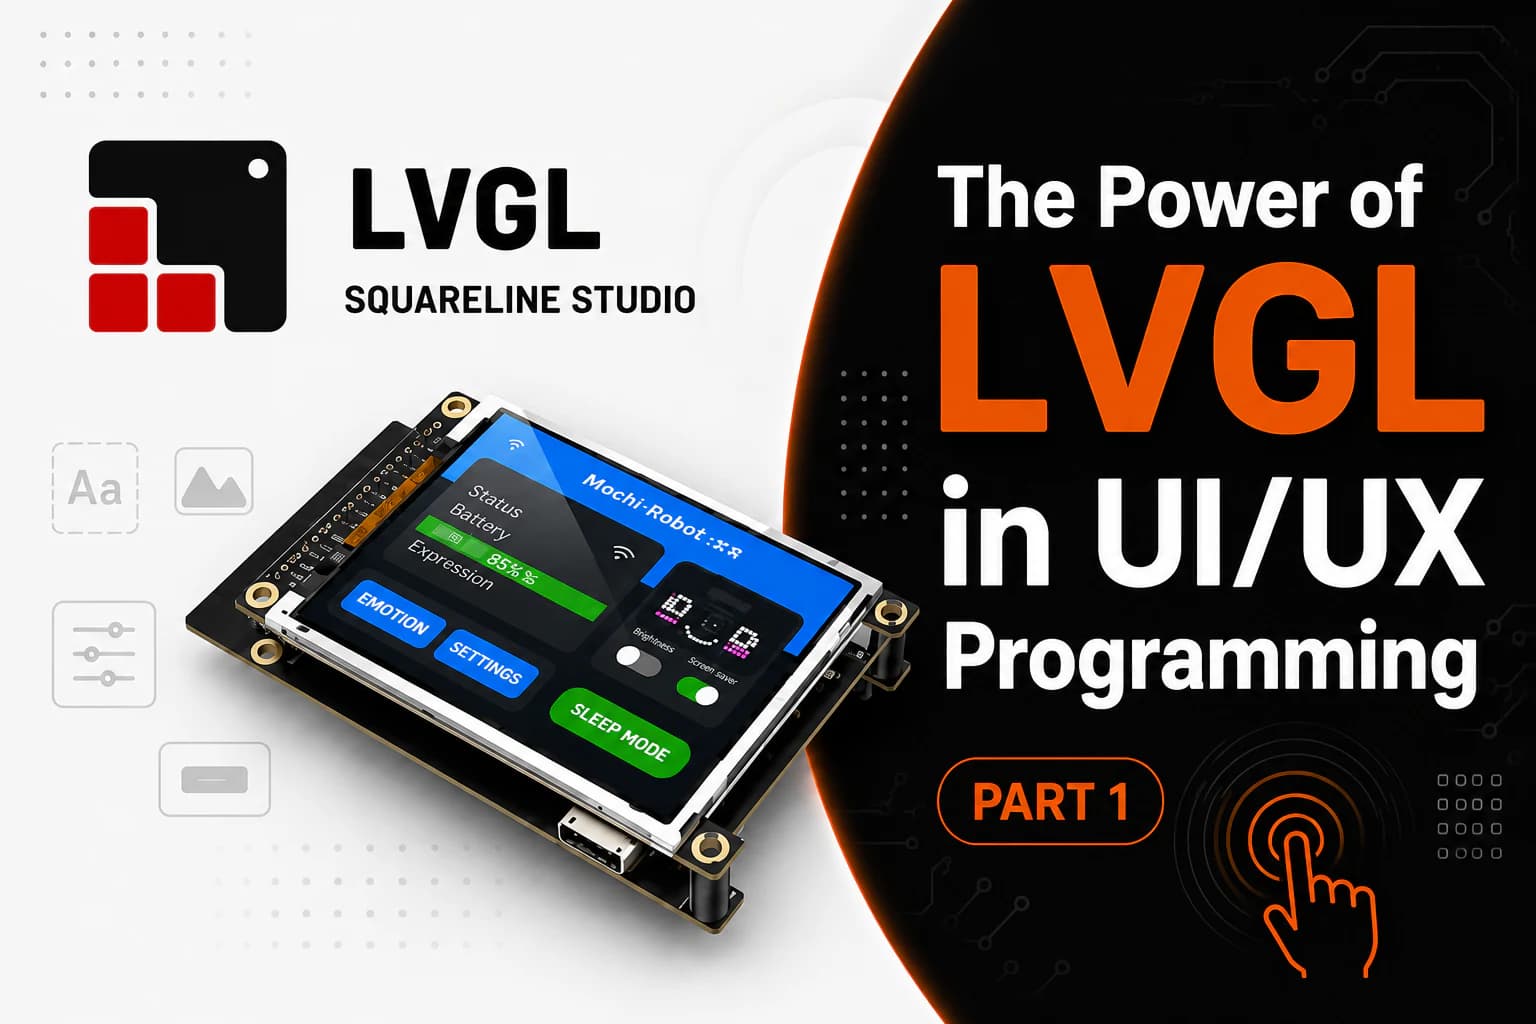
How LVGL helps build emotional interfaces for Mochi Robot, including expressions, menus, battery status, and UI on small embedded displays.
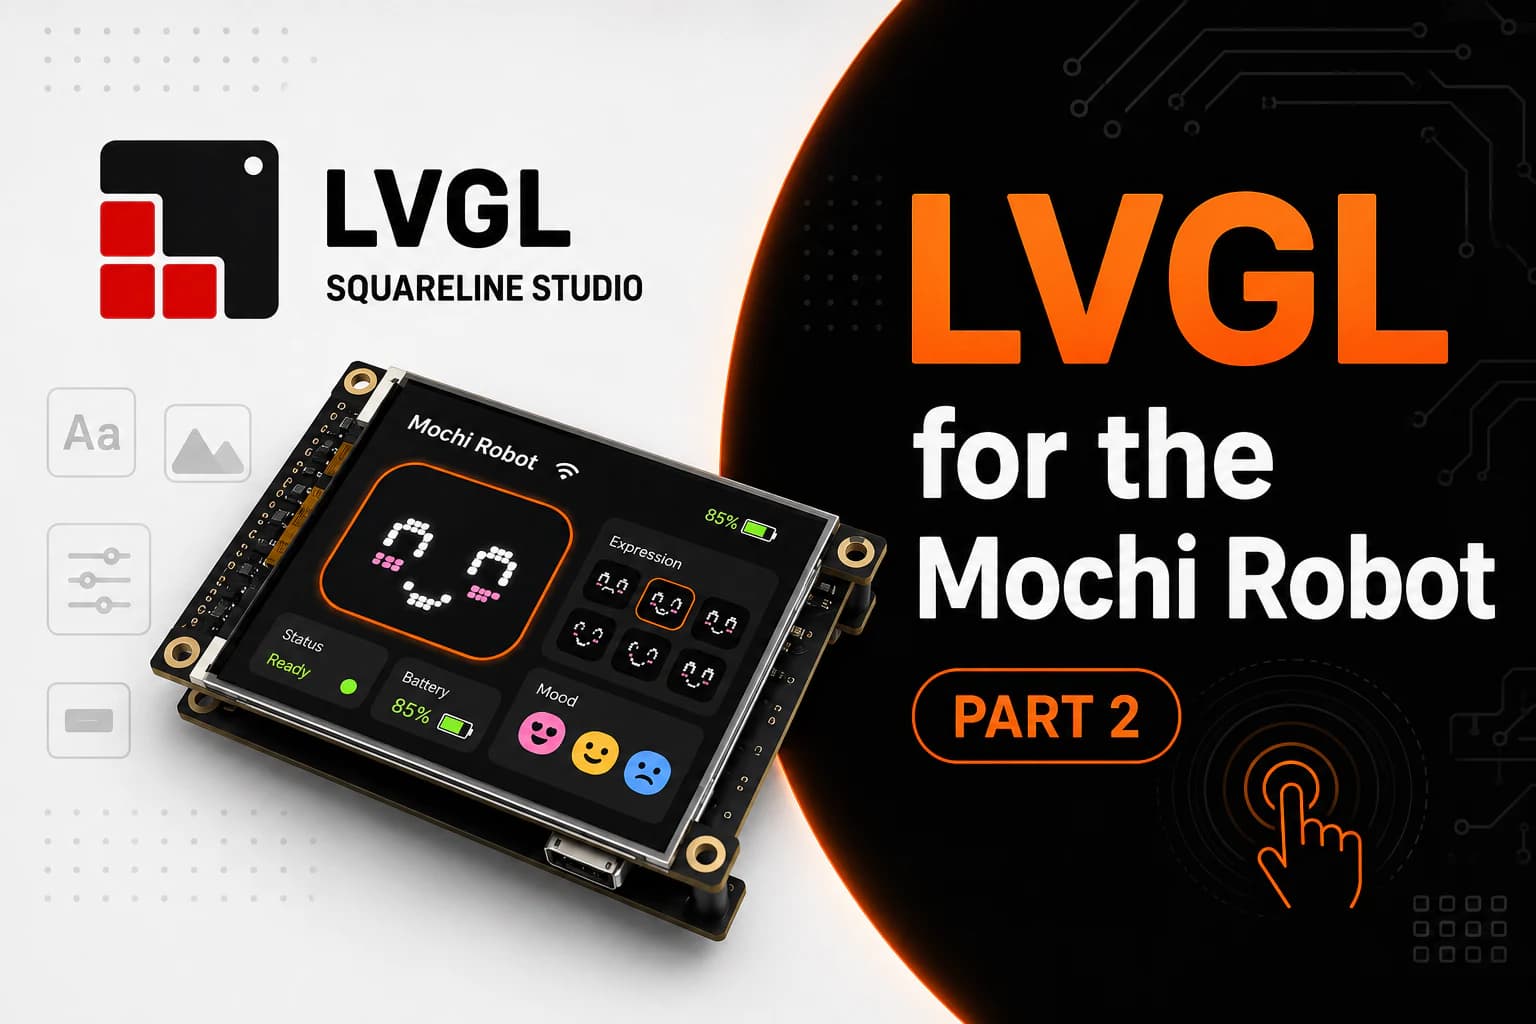
Part 2 of the Mochi LVGL series, covering faces, expressions, battery status, connectivity, screens, components, and UI states.
What embedded UI means for small devices, why small screens have small budgets, and why it deserves attention as its own discipline.
Early principles for firmware on a small embedded product: scope, module boundaries, logging, and handling errors without guessing.
The first Mochi devlog: early hardware questions, first firmware decisions, and what already went wrong.
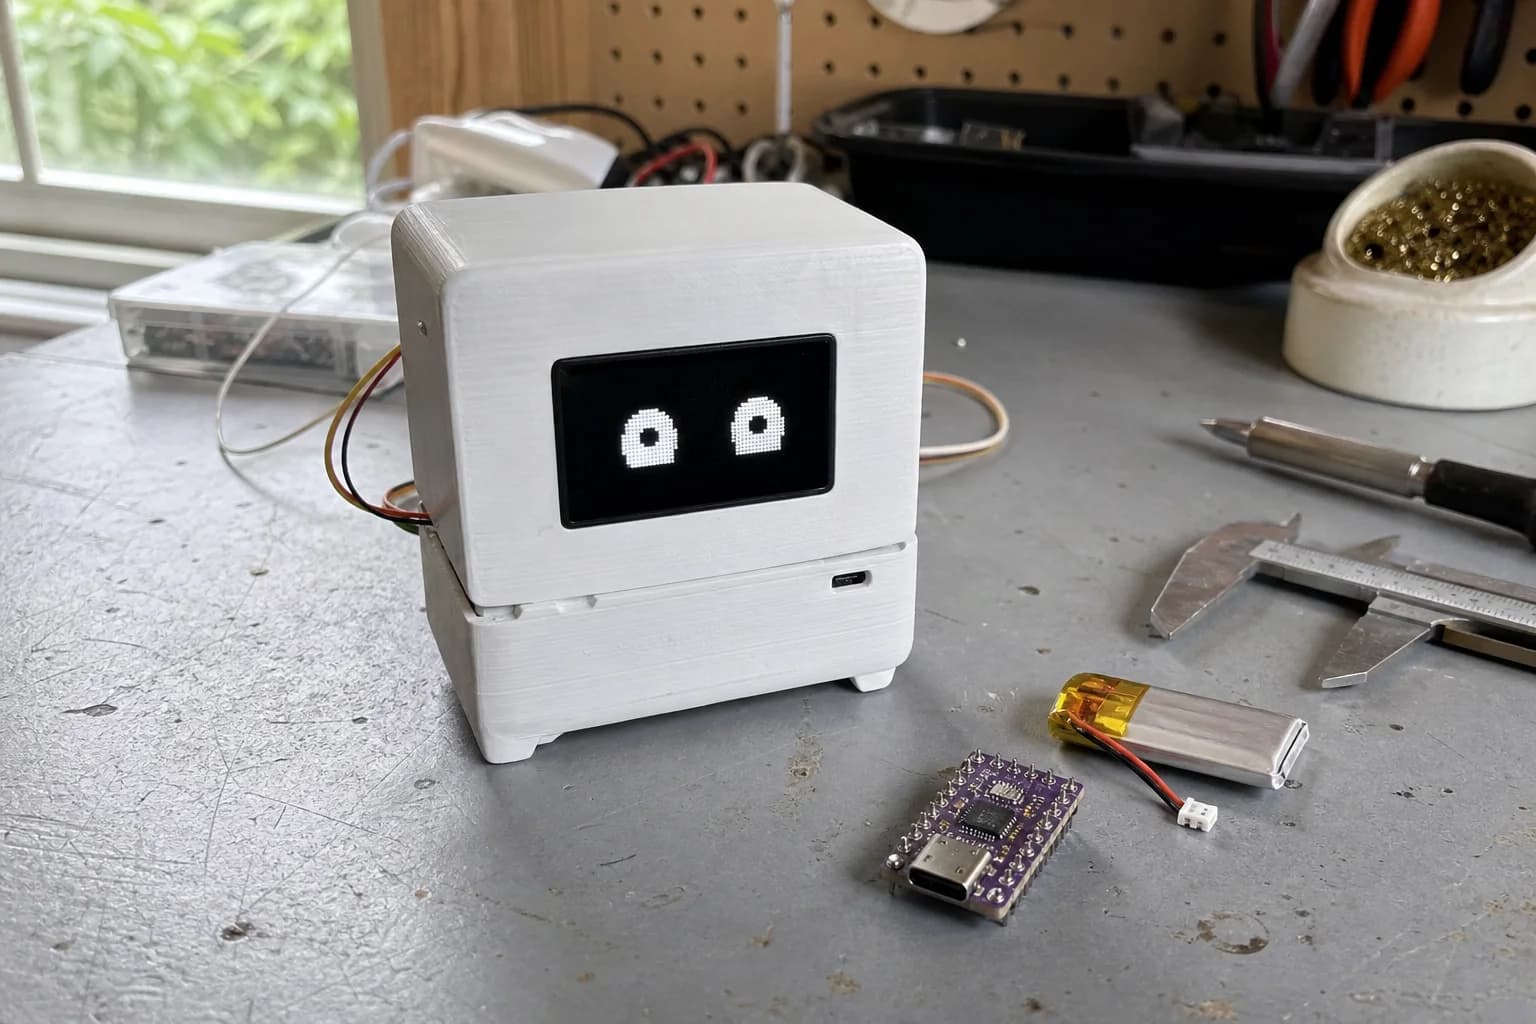
A short introduction to Mochi, a small robot developed as an exercise in hardware, firmware, and product experience.
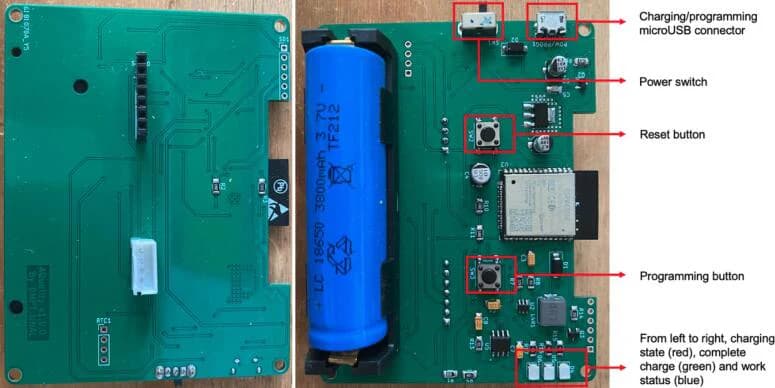
Initial principles for designing hardware for a small product: scope, power, PCB layout, firmware, and debugging.
How Nastrotek prepares and shares design files, templates, source code, and free documents clearly.
Popular
Nastrotek uses cookies for analytics and ad personalization to help us understand how the site is used. You can accept or decline non-essential cookies. Privacy Policy